

Underwater single-photon LIDAR optical system design
-
摘要:
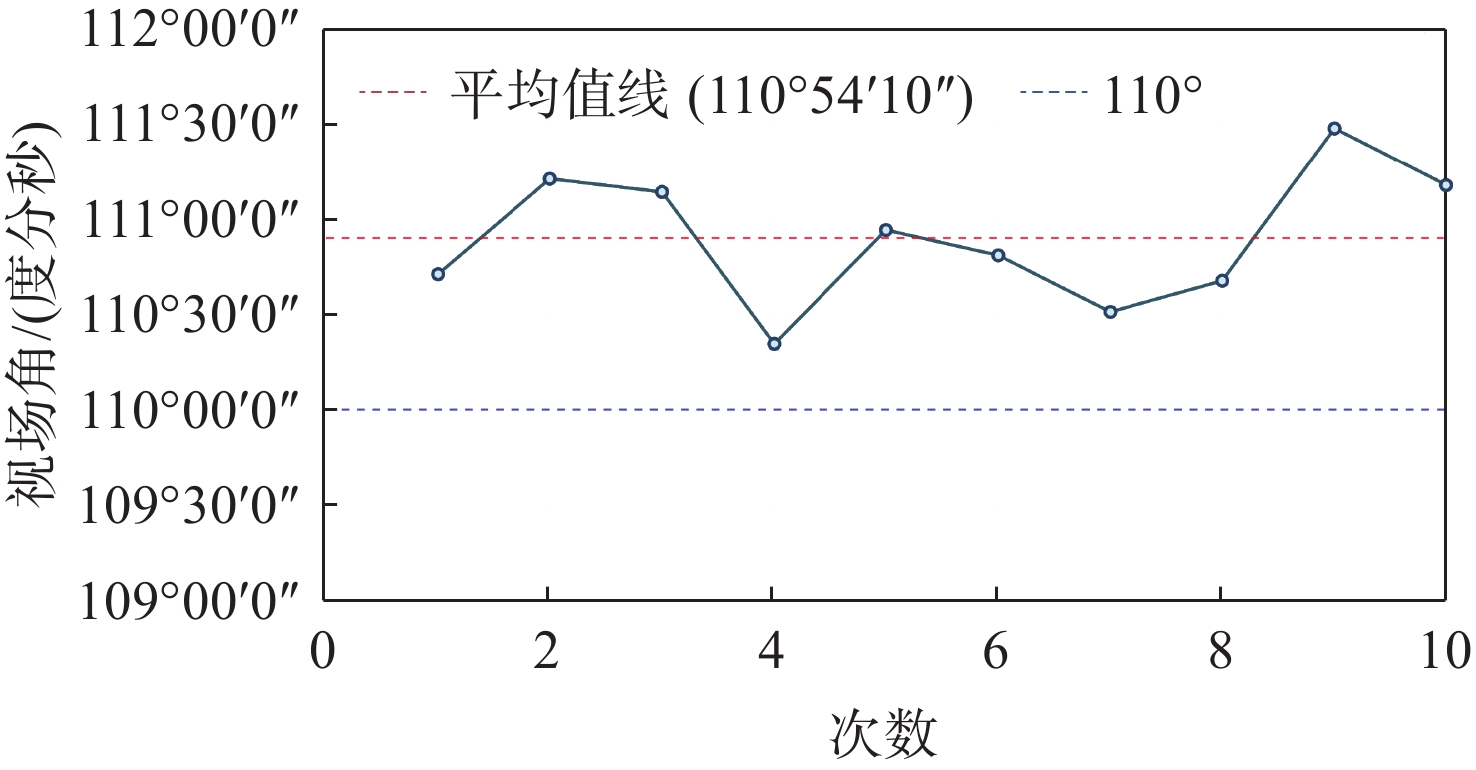
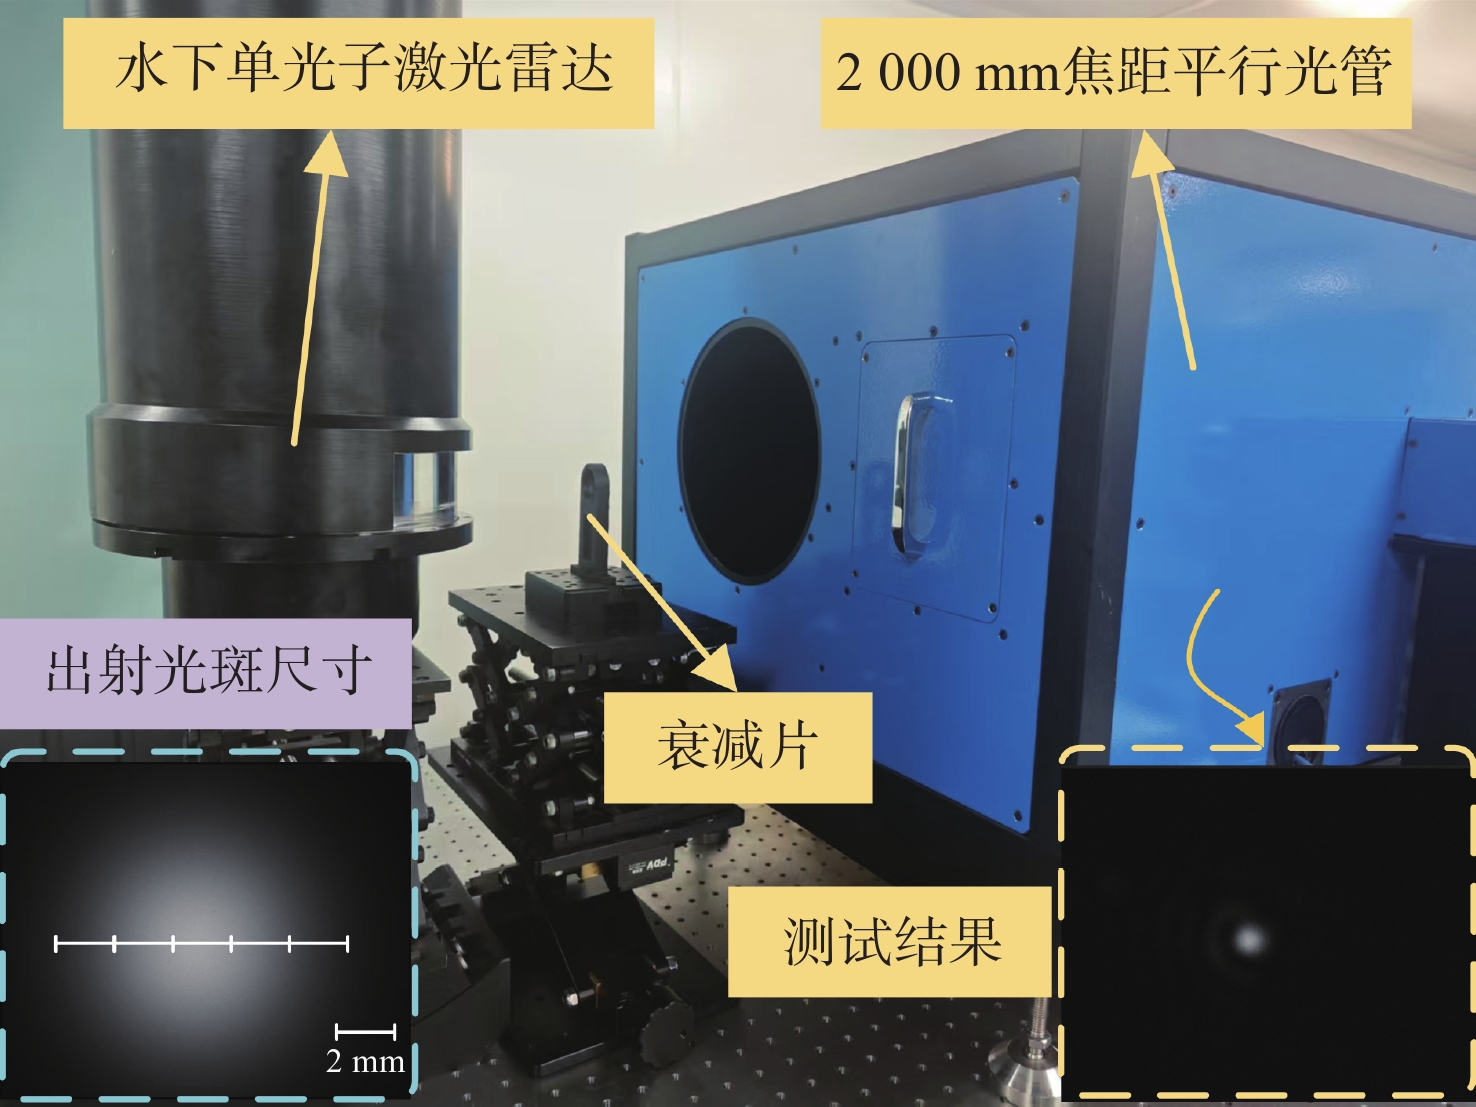
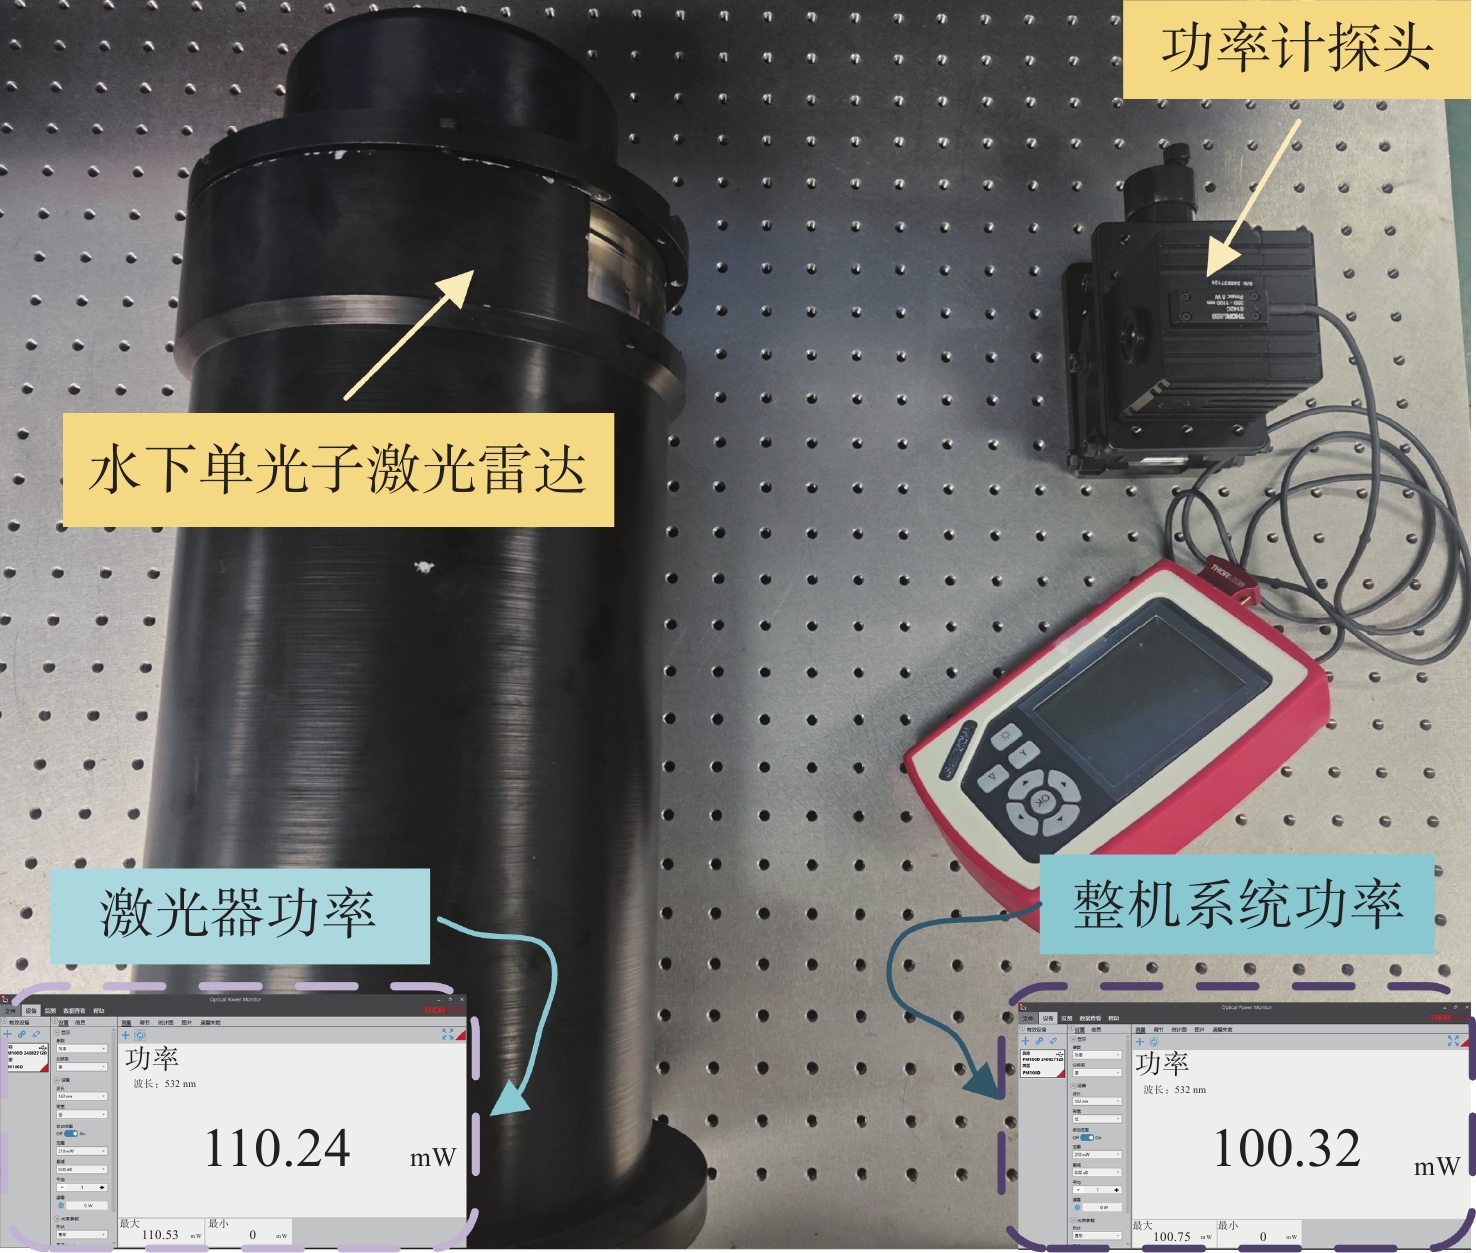
针对单光子激光雷达在水下广域探测中难以兼顾大扫描视场与系统小型化的问题,本文提出基于转镜扫描与环形隔水视窗密封相结合的技术方案。通过构建扫描角度、光束口径与转镜几何尺寸之间几何关系,结合环形隔水视窗构型,在满足大扫描视场的同时实现系统小型化;采用光线追迹方法建立光学系统初始结构,利用柱面光学元件的成像与补偿原理,改善激光束经环形隔水视窗跨介质传输后光束质量退化的问题,并结合望远系统开展一体化优化设计,进一步提升光束质量。实验结果表明,该系统可实现110°扫描视场,发射激光光束质量因子优于1.3倍衍射极限,发散角为0.084 mrad,传输效率为91.00%,在水质衰减系数为0.184 m−1环境中的最大探测距离为24 m。该系统兼具大视场扫描能力和小型化结构优势,可为水下广域探测装备的工程化应用提供参考。
Abstract:To address the challenge of simultaneously achieving a large scanning field of view and system miniaturization in underwater single-photon LiDAR, this paper proposes a technical solution based on mirror scanning and a sealed annular window. By establishing the geometric relationship between scanning angle, beam aperture, and mirror size, and integrating an annular water-isolated window structure, the system achieves miniaturization while maintaining a large scanning field of view. The initial optical system structure is built using ray tracing, and by applying the imaging and compensation principles of cylindrical optical elements, it improves the degradation of beam quality after passing through the annular window across different media. Integrated optimization with the telescope system further enhances beam quality. Experimental results demonstrate that the proposed system achieves a scanning field of view of 110°, a beam quality factor of less than 1.3 times the diffraction limit, a beam divergence angle of 0.084 mrad, and a transmission efficiency of 91.00%. The maximum detection range reaches 24m in water with an attenuation coefficient of 0.184m-1. The proposed system provides both wide-field scanning capability and compact structural advantages, offering a potential solution for the engineering development of underwater wide-area detection platforms.
-
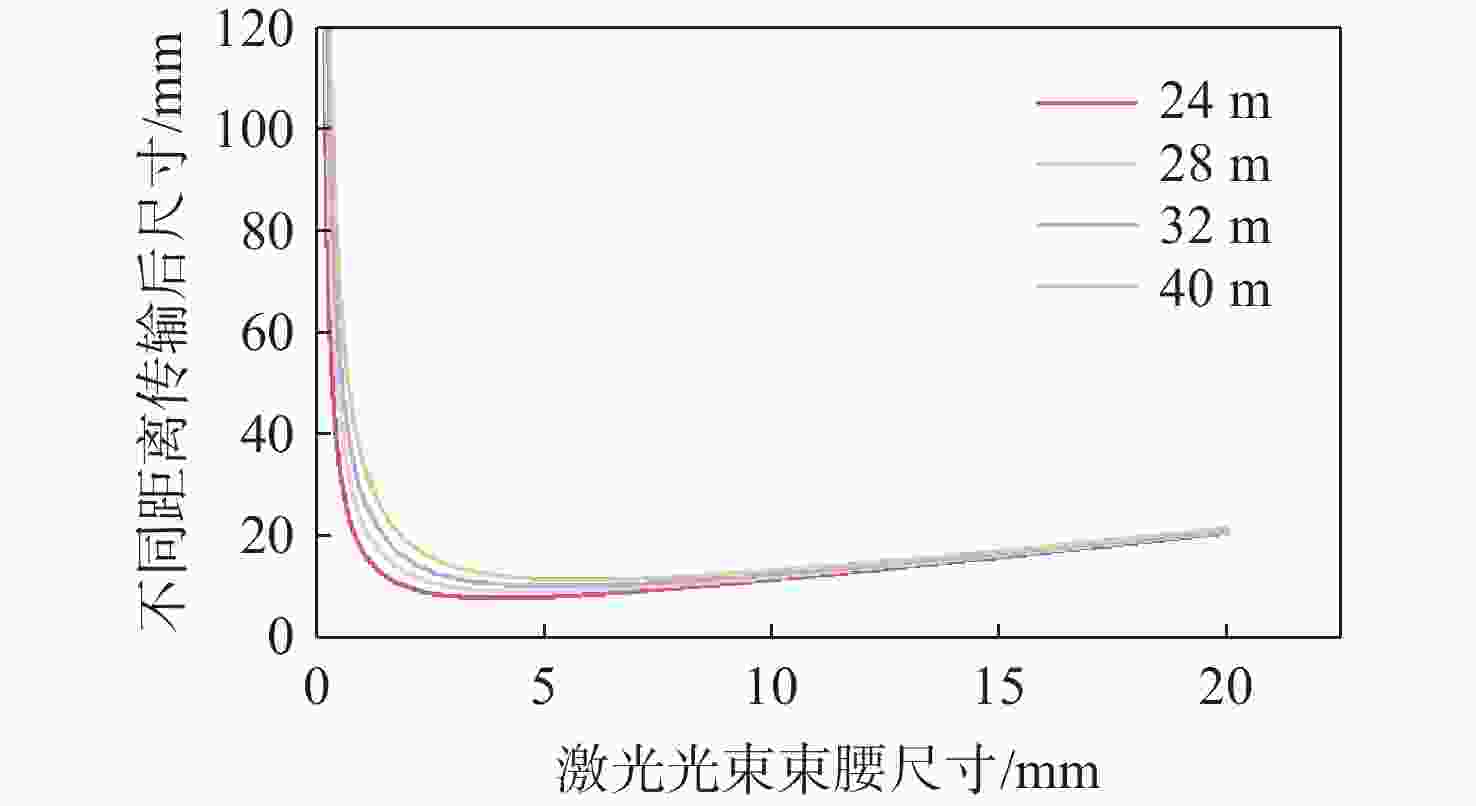
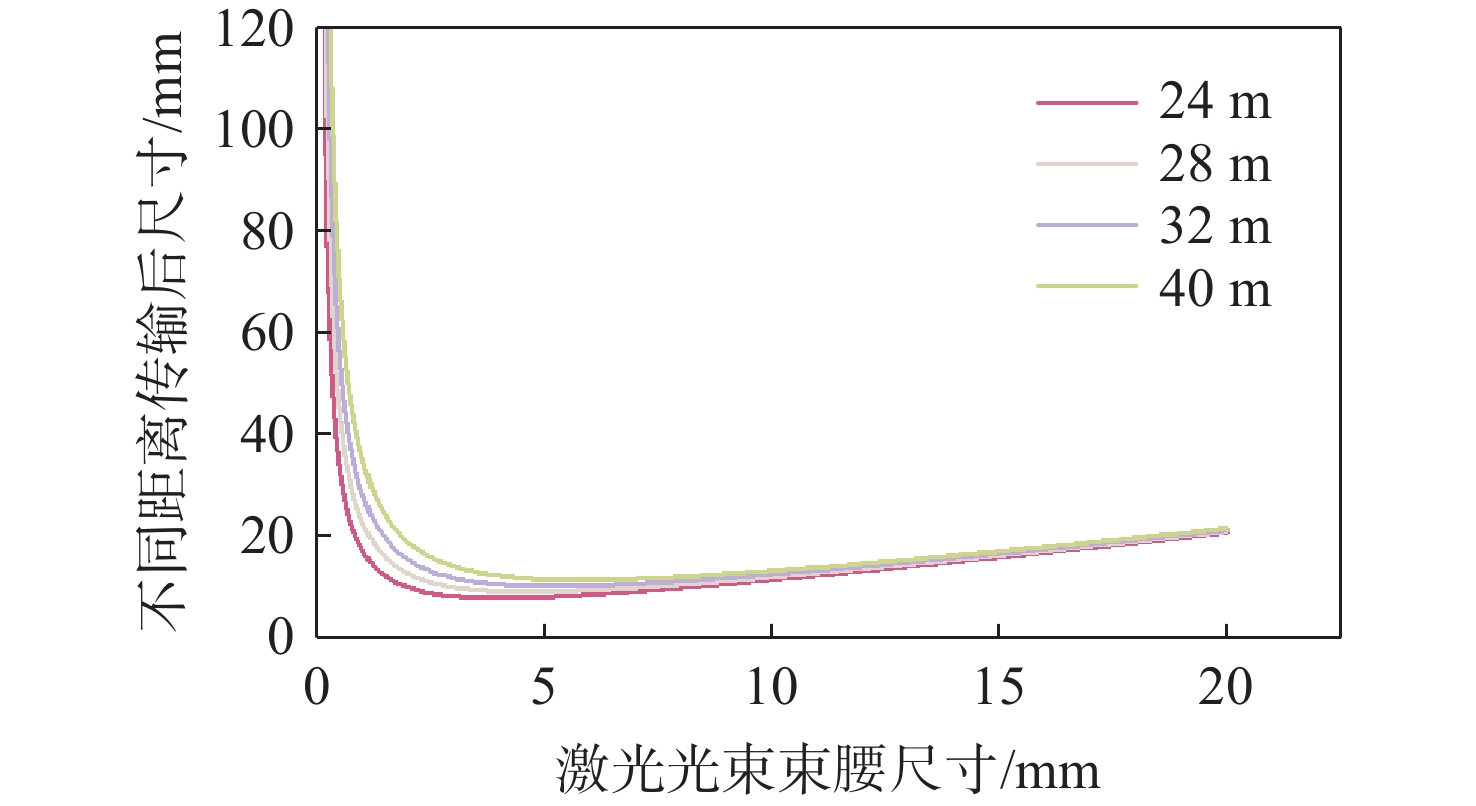
图 1 不同束腰激光光束传输不同距离后的光斑大小
Figure 1. The spot size of different waist laser beams after tr-ansmitting at different distances
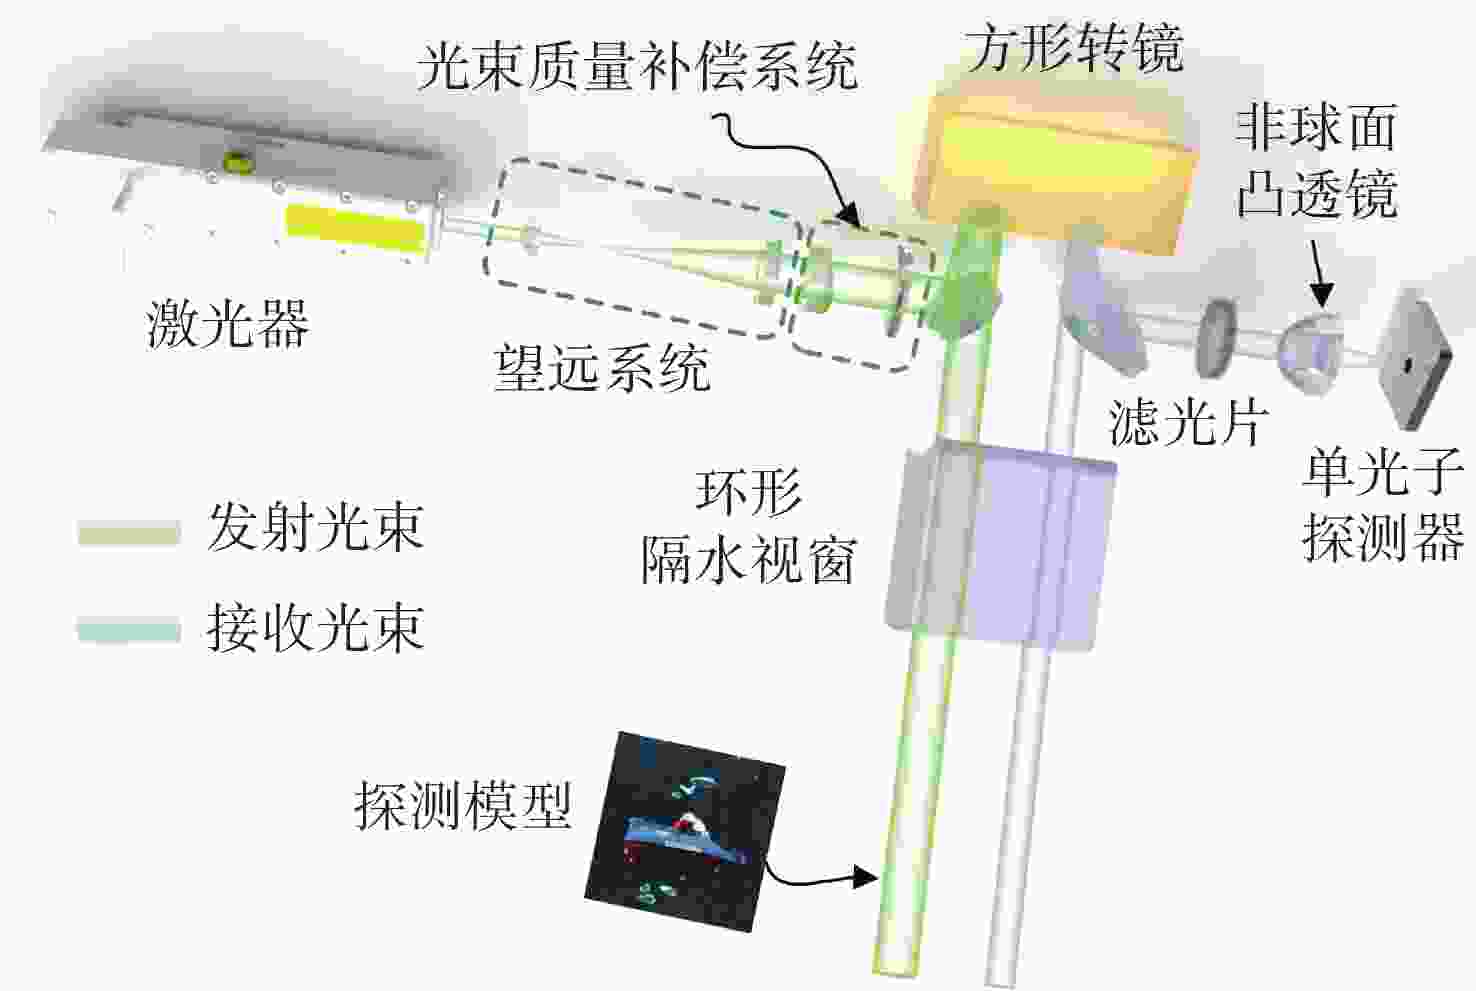
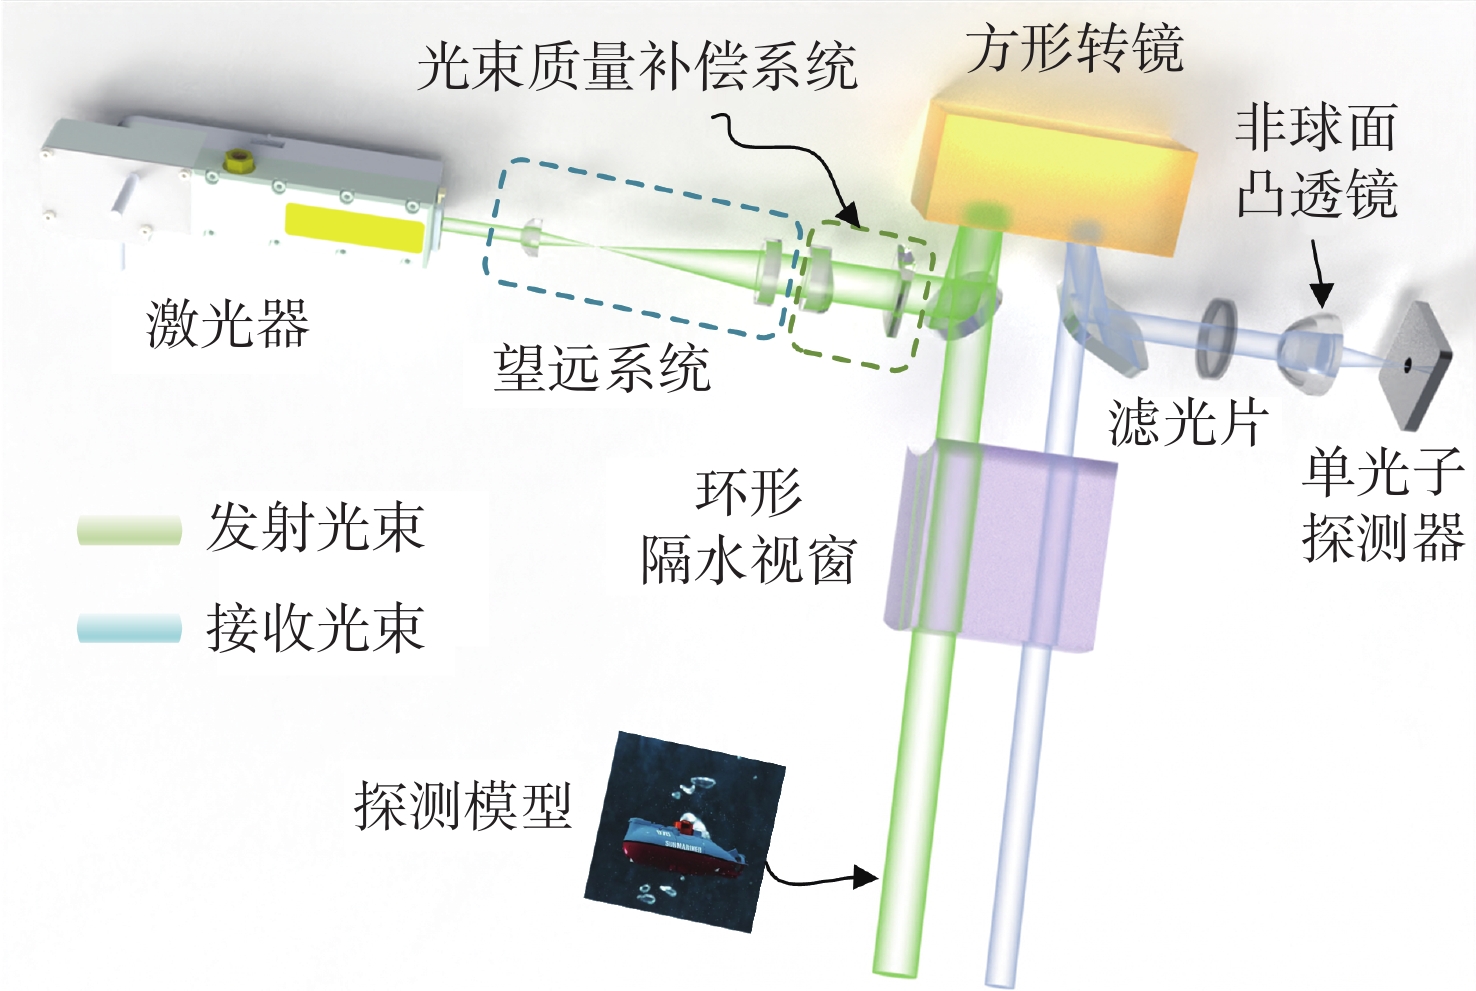
图 2 水下单光子激光雷达光学系统整体结构图
Figure 2. The overall structure diagram of the optical system of the underwater single-photon laser radar
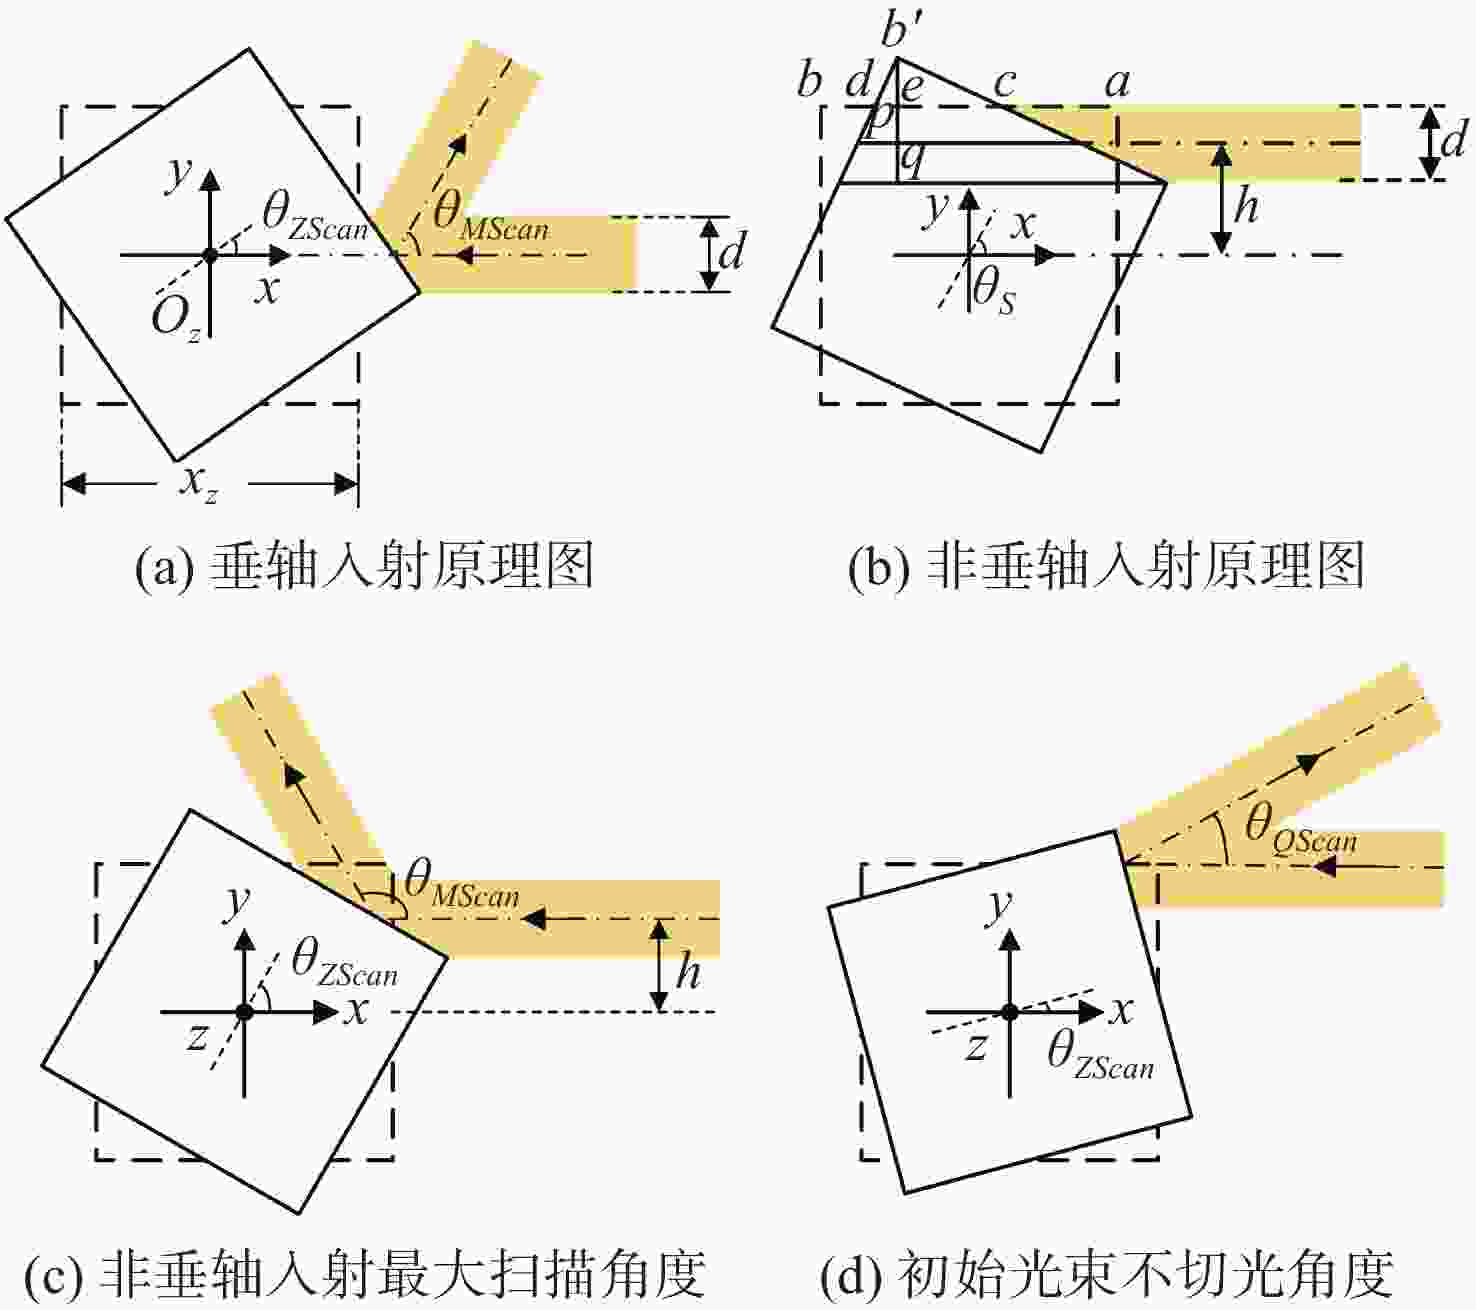
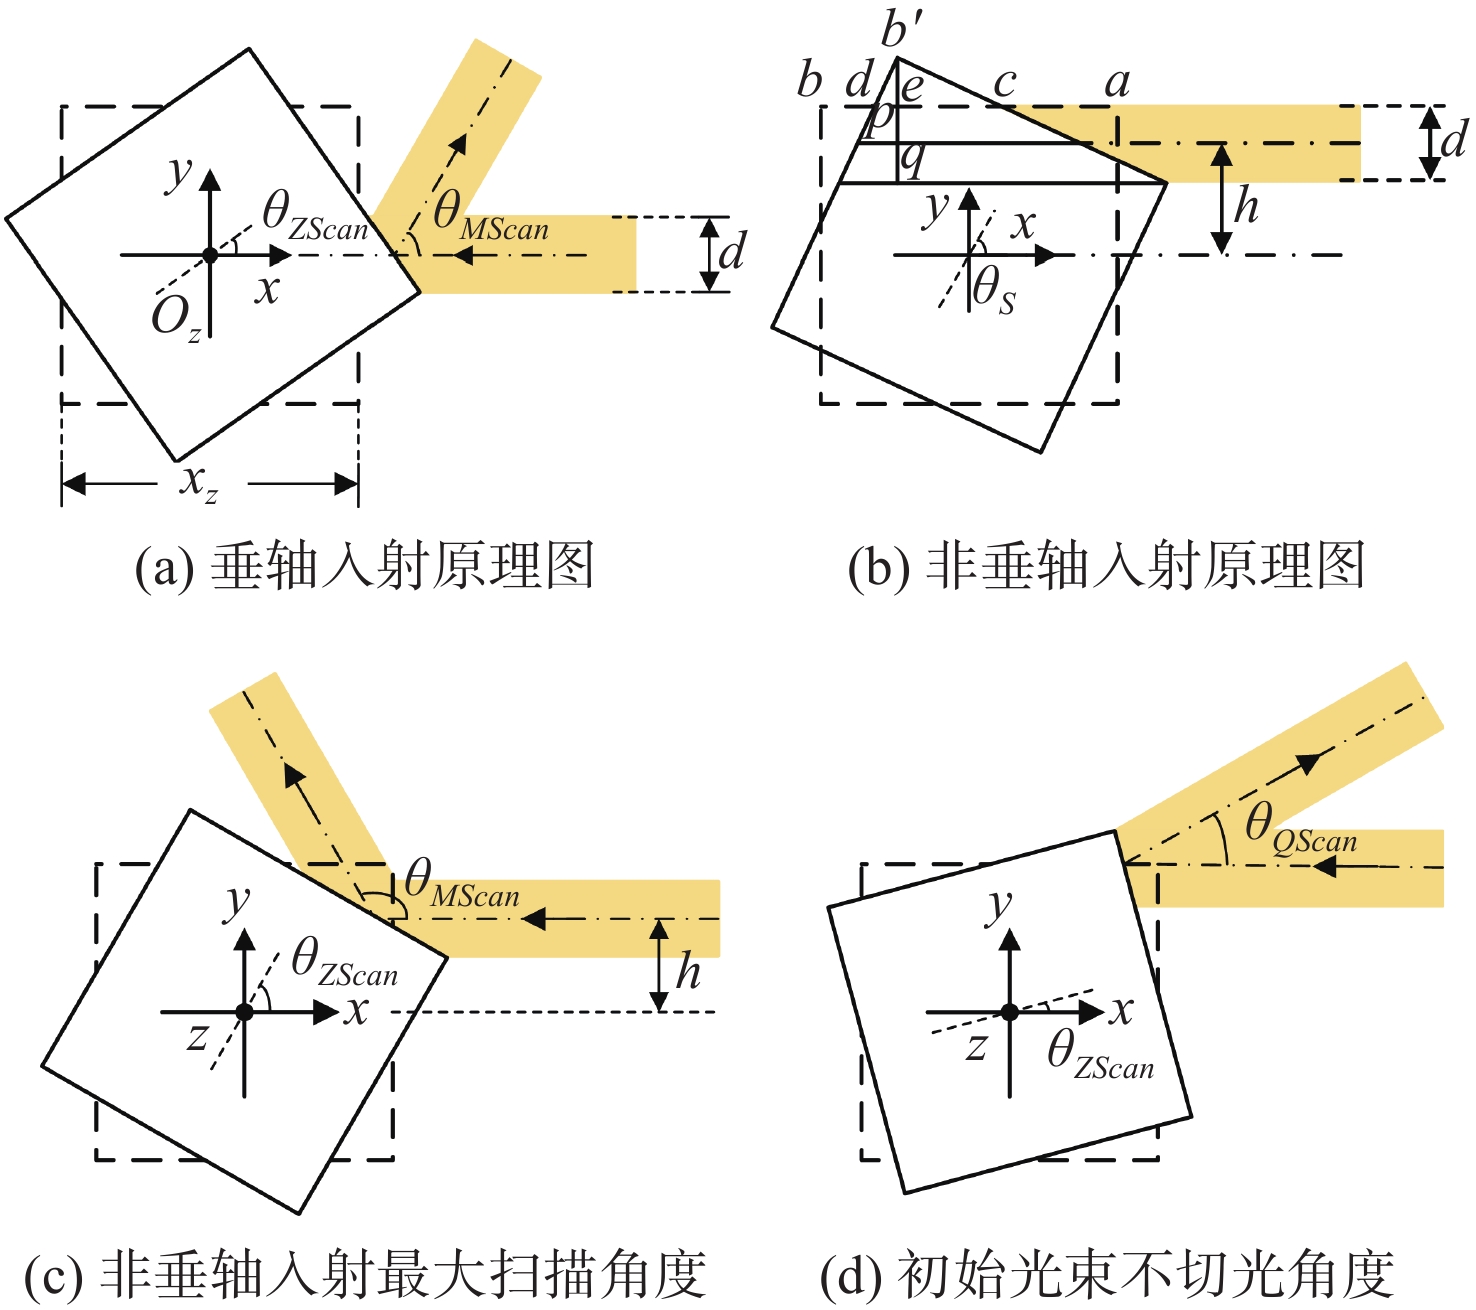
图 3 激光光束在不同位置时转镜扫描角度原理图
Figure 3. The principle diagram of scanning angle of rotating mirror when laser beam is in different positions
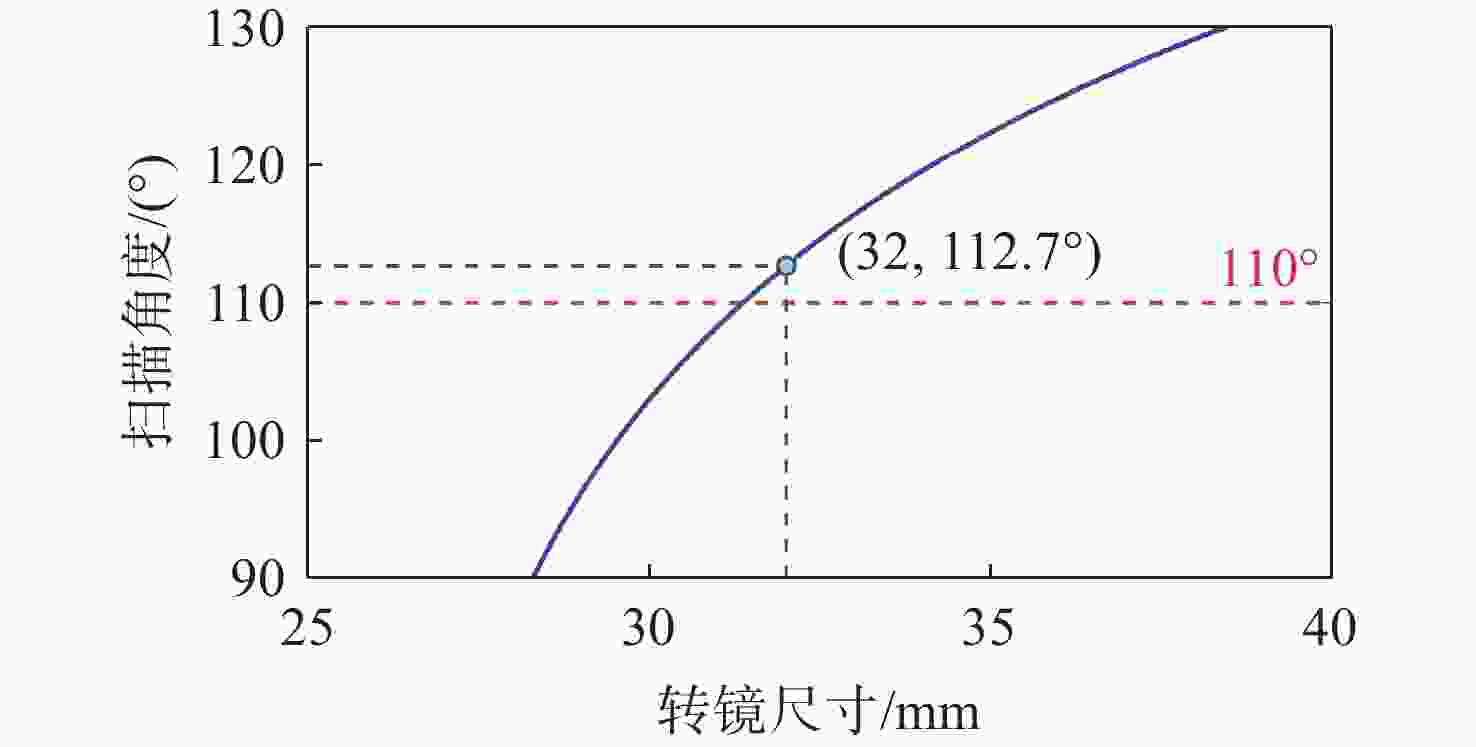
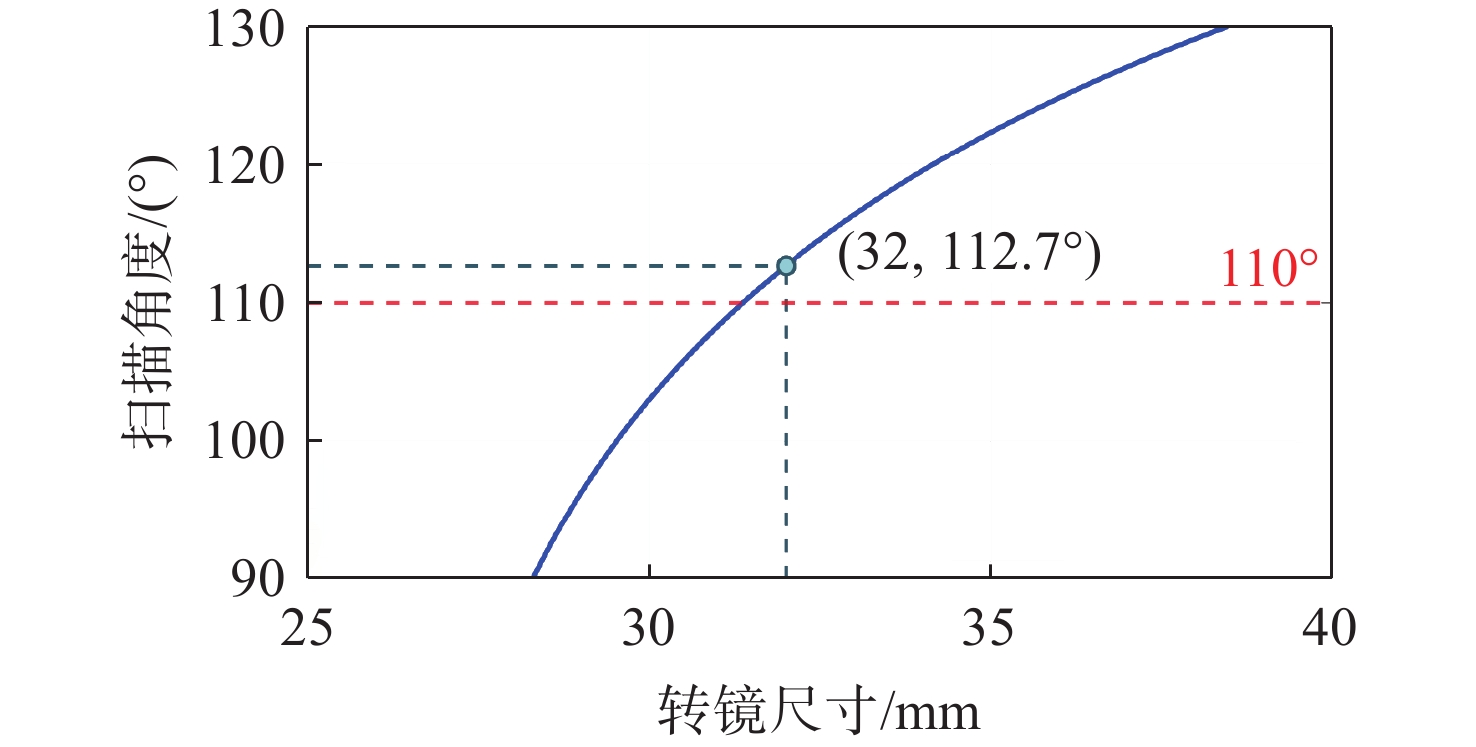
图 4 转镜尺寸与扫描角度之间关系图
Figure 4. The relationship between the size of the rotating mirror and the scanning angle
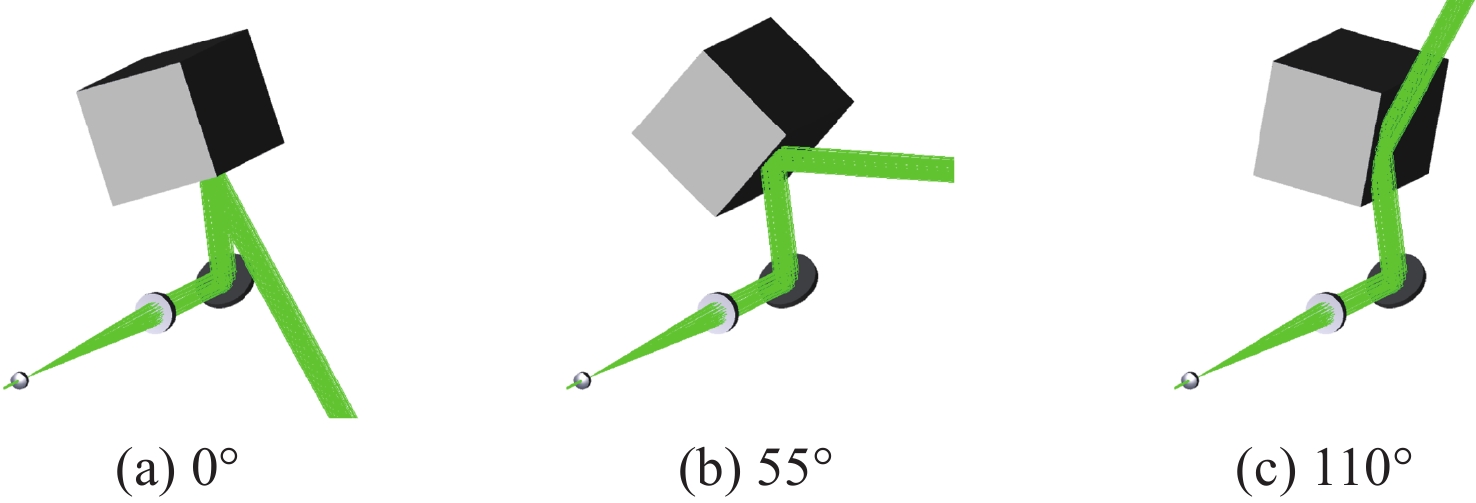
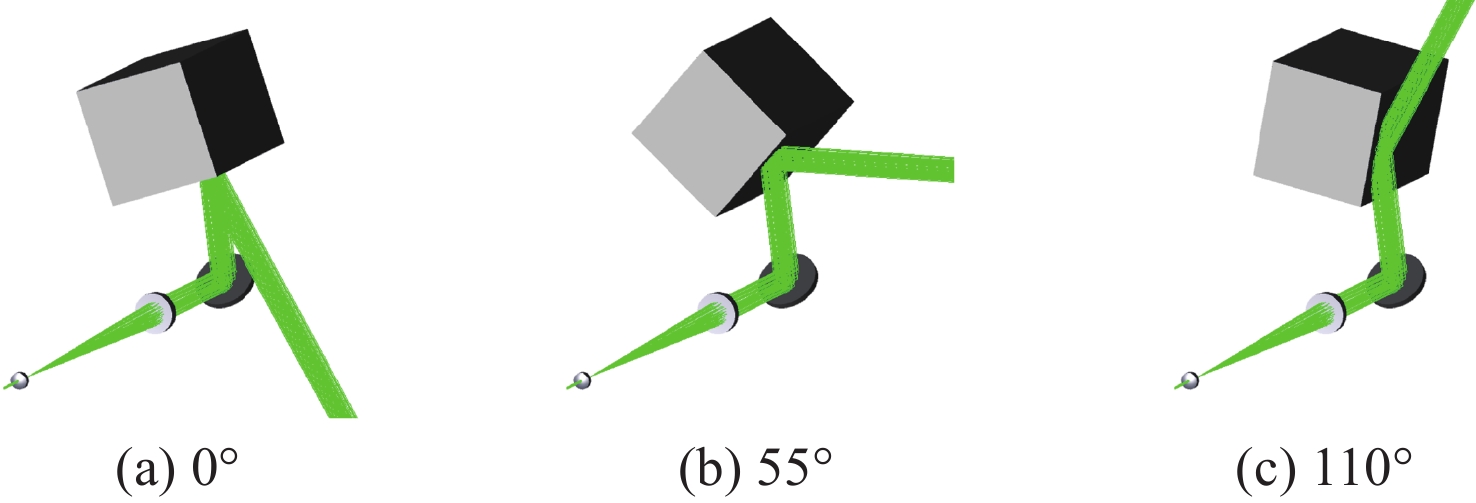
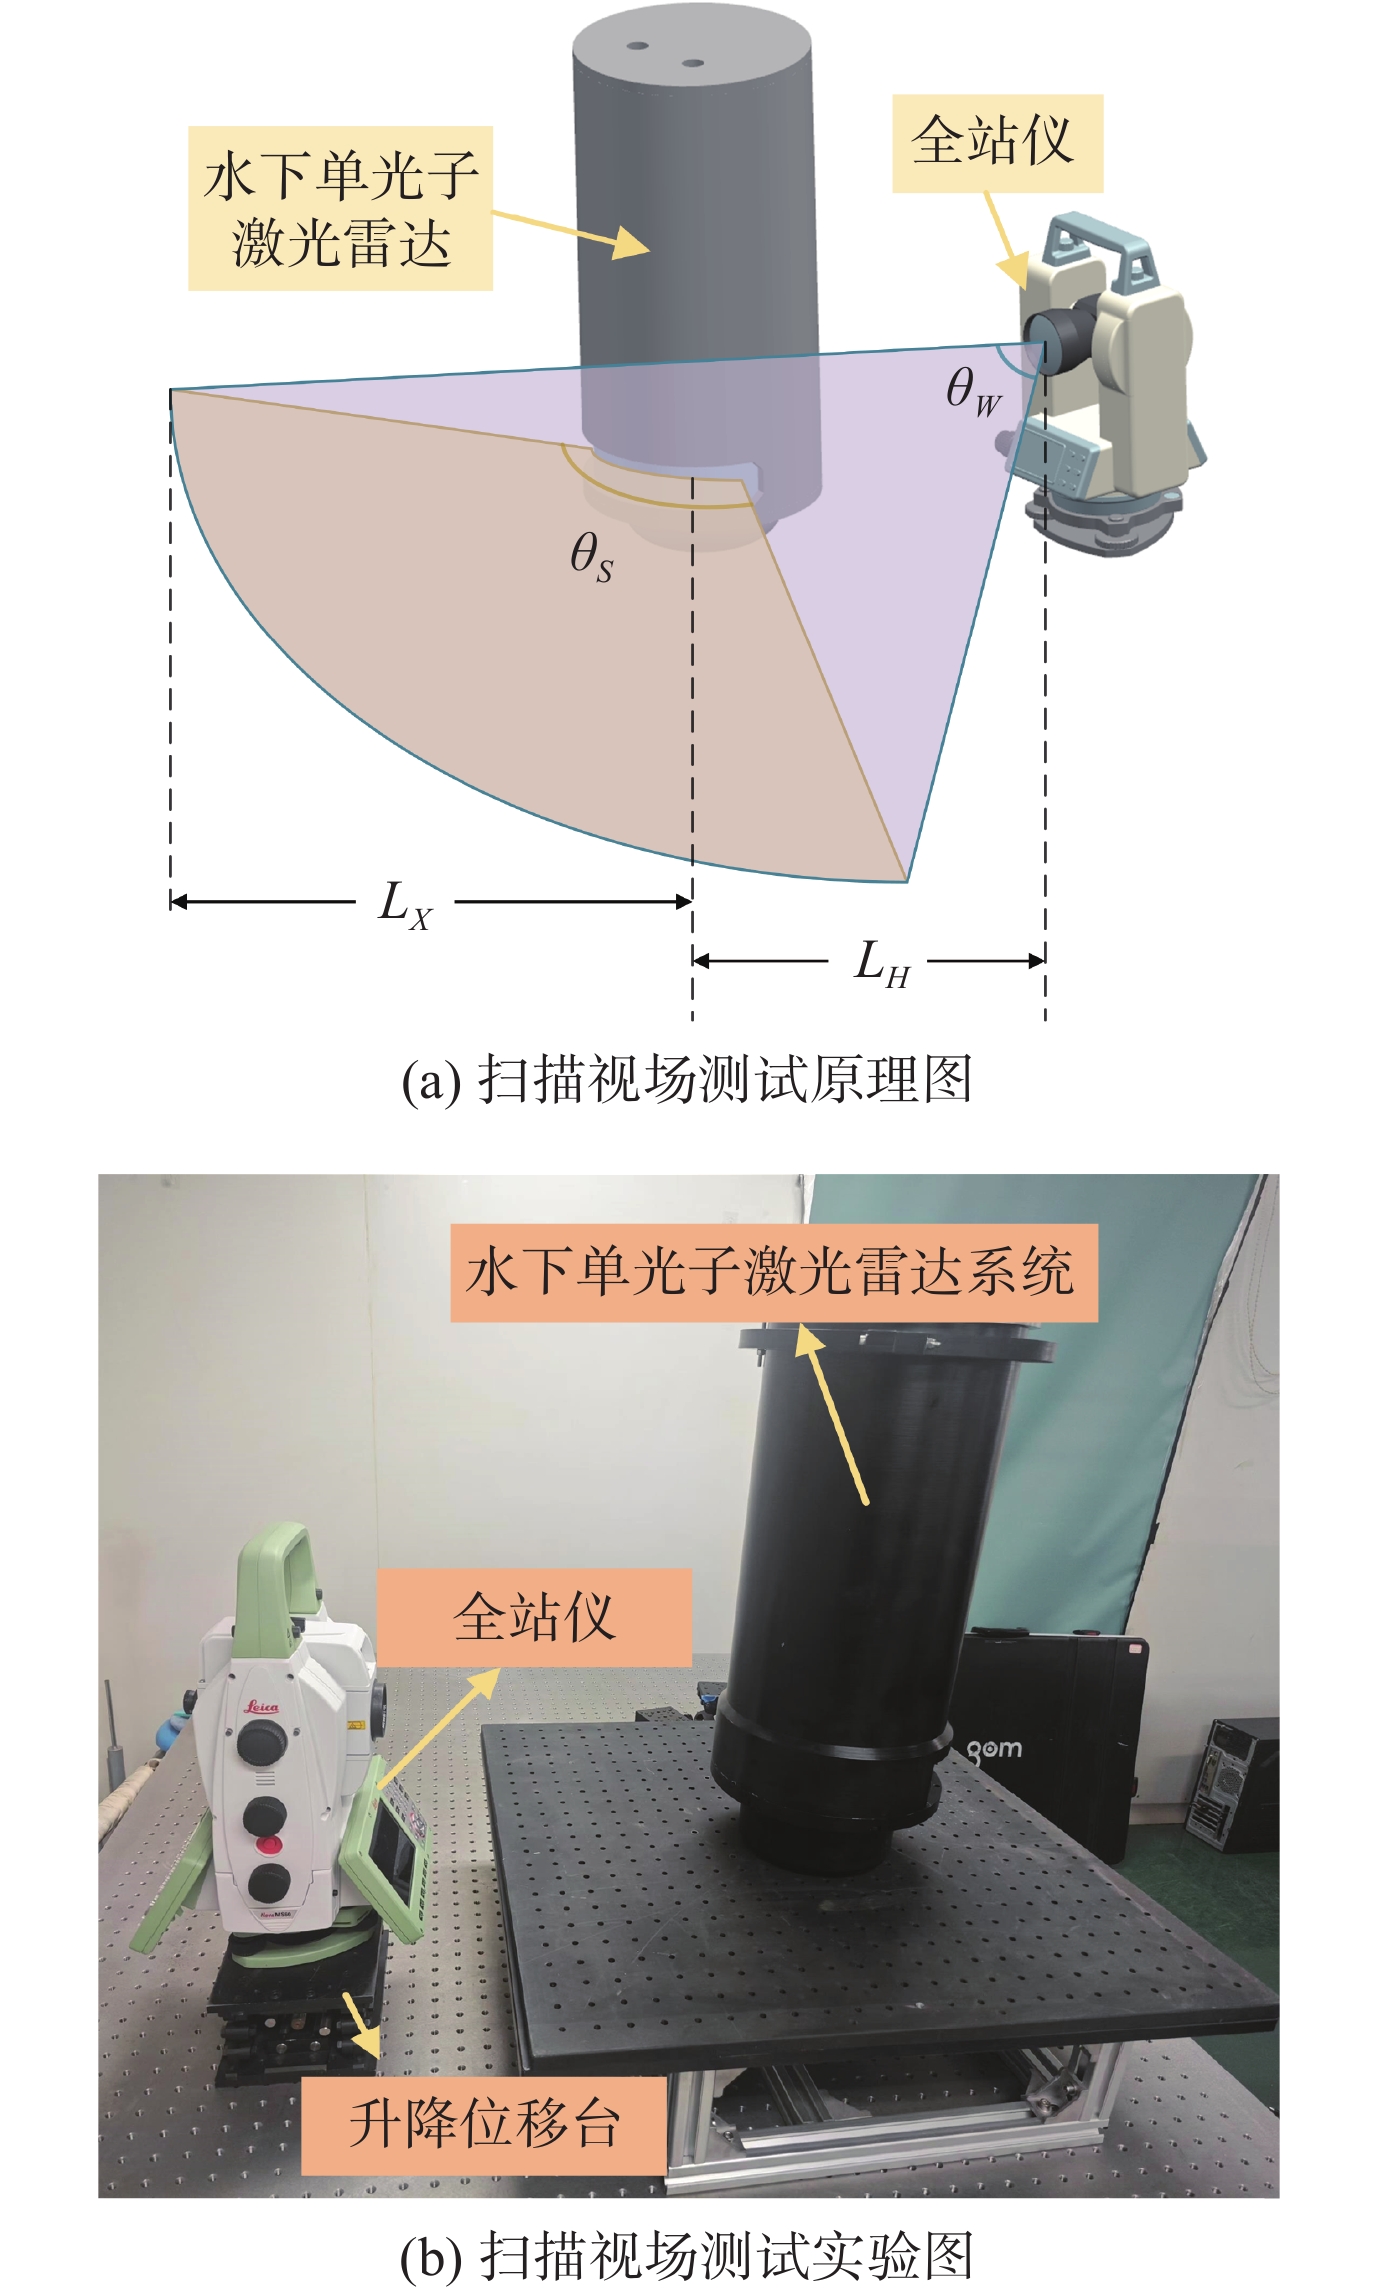
图 5 无视窗时转镜扫描角度仿真图
Figure 5. Simulation diagram of scanning angle of rotating mirror without window
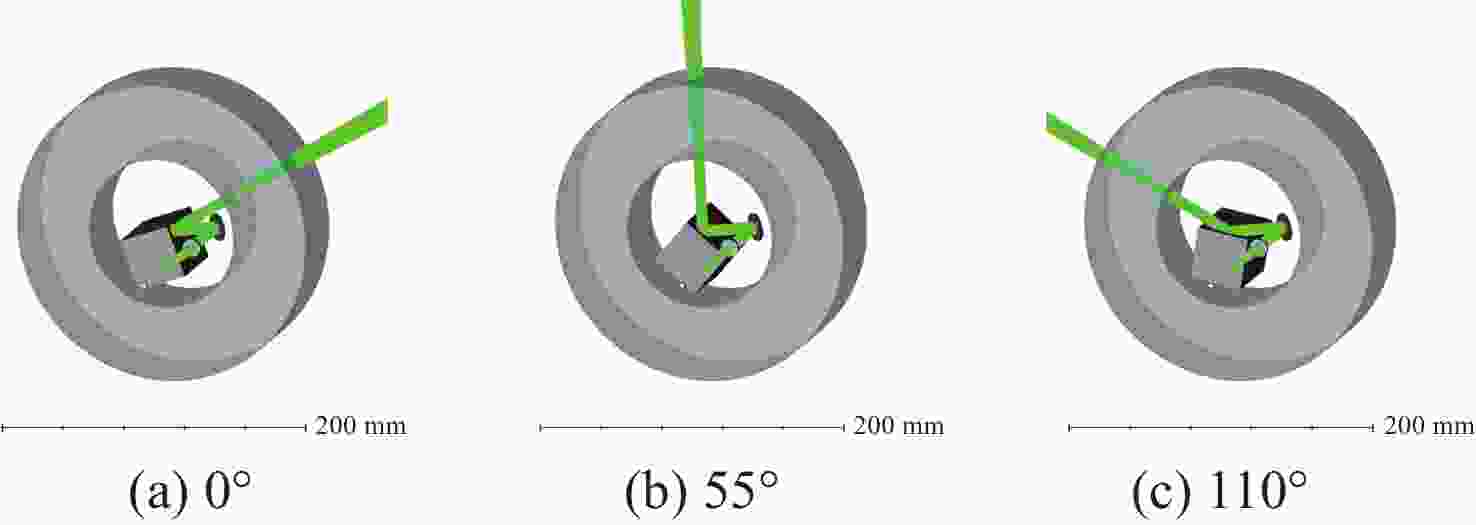
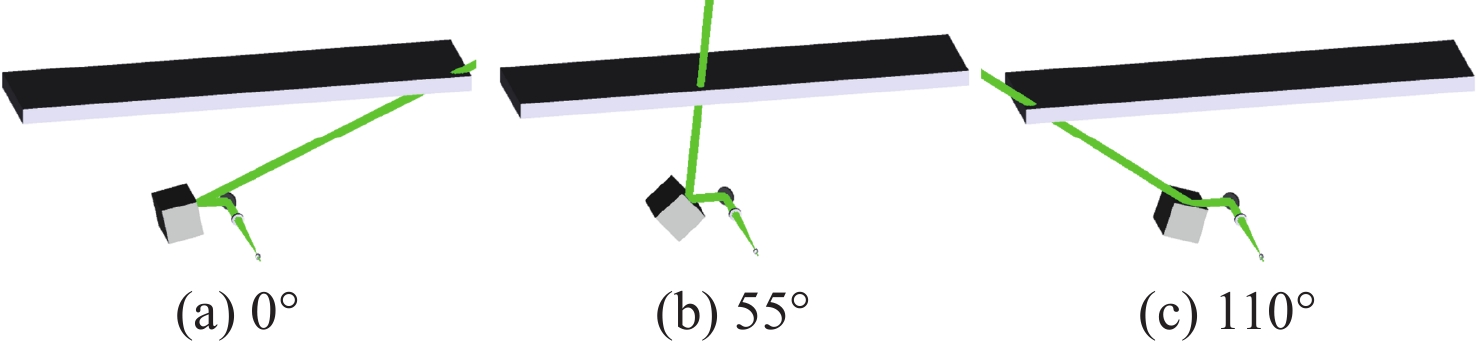
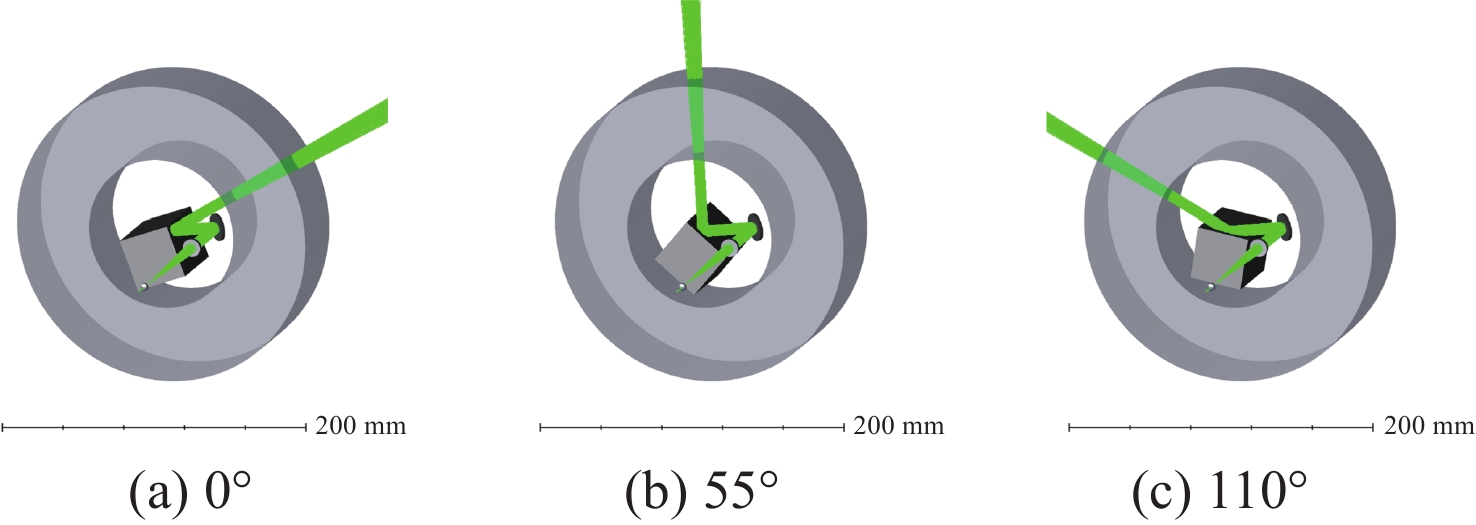
图 7 环形视窗转镜扫描角度仿真图
Figure 7. Simulation diagram of scanning angle of annular window rotating mirror
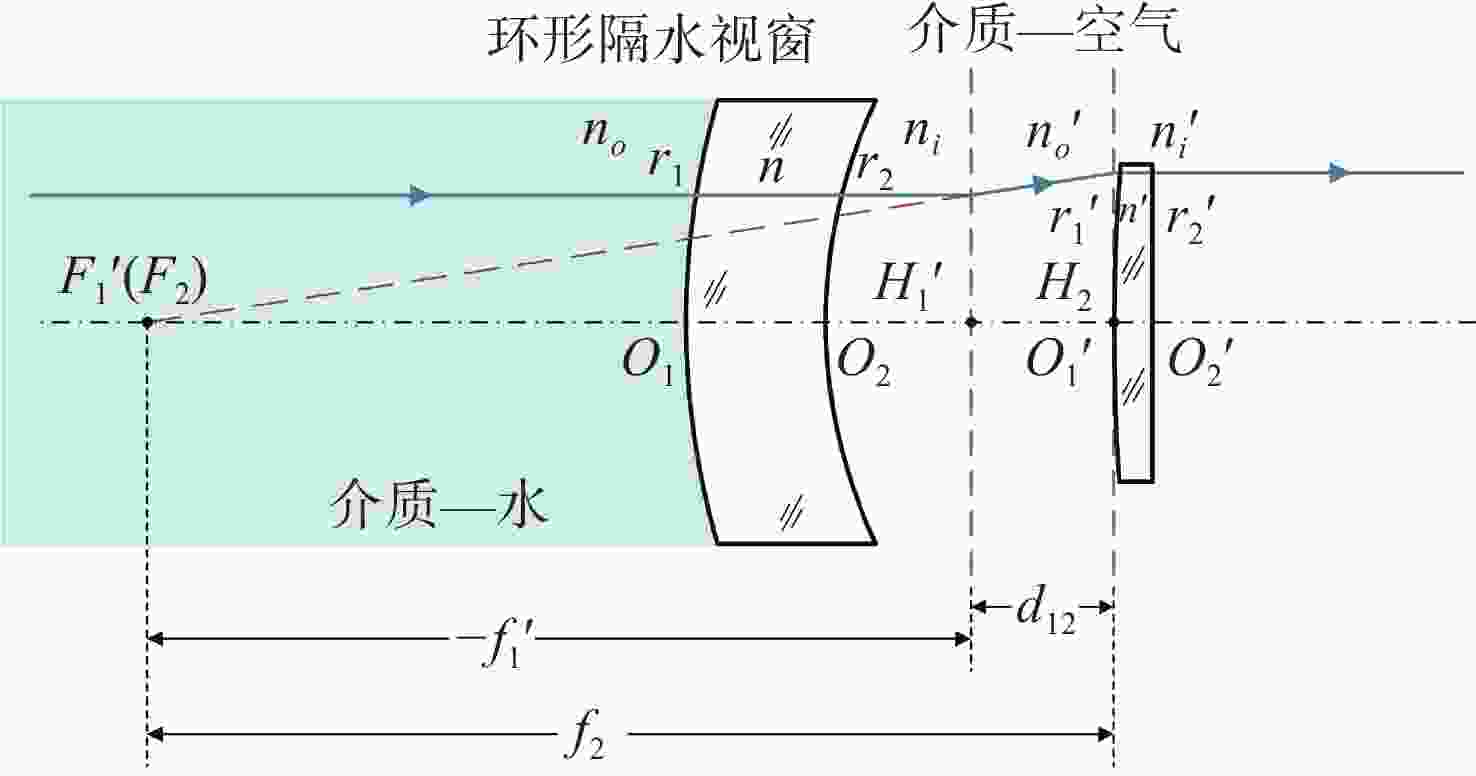
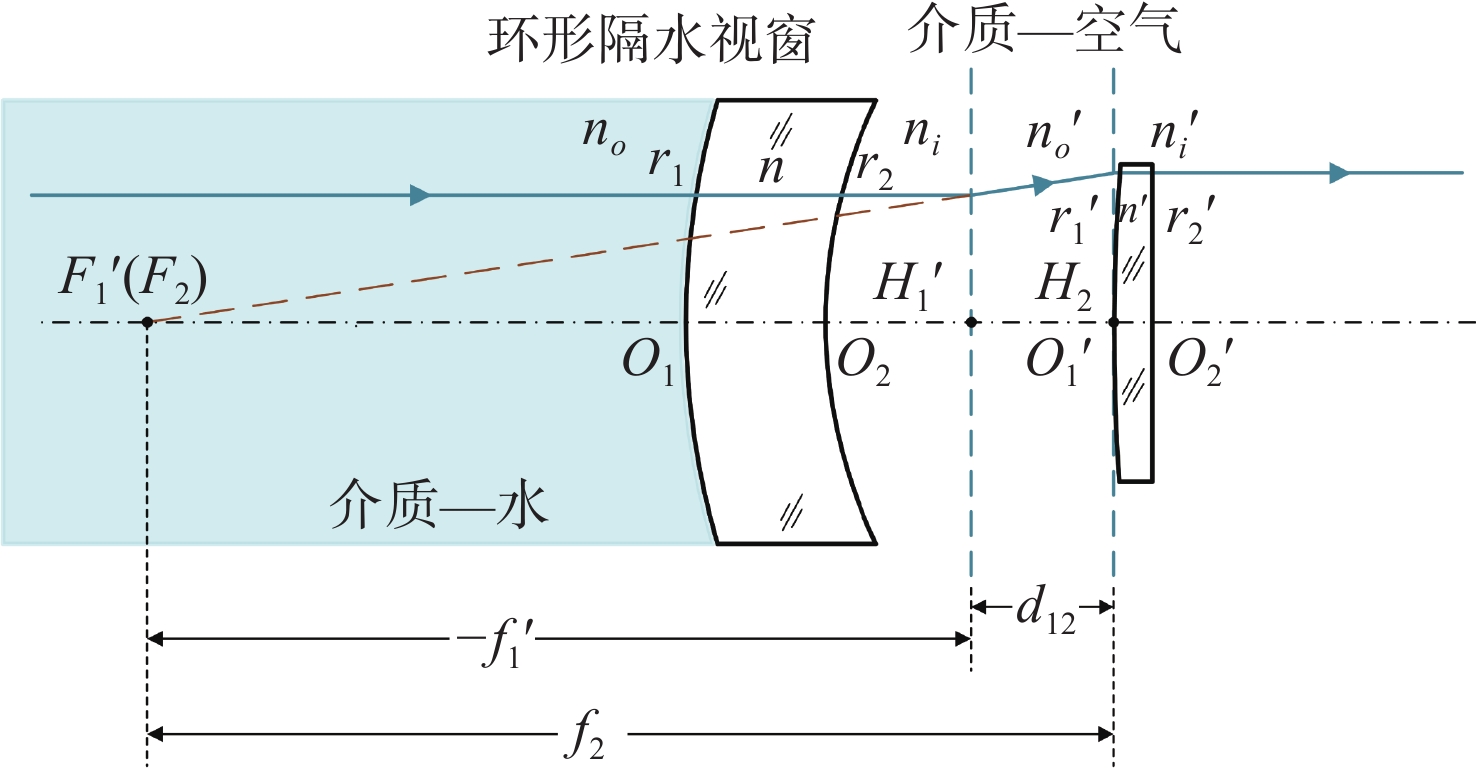
图 8 激光光束准直程度补偿原理图
Figure 8. Laser beam collimation degree compensation schematicdiagram
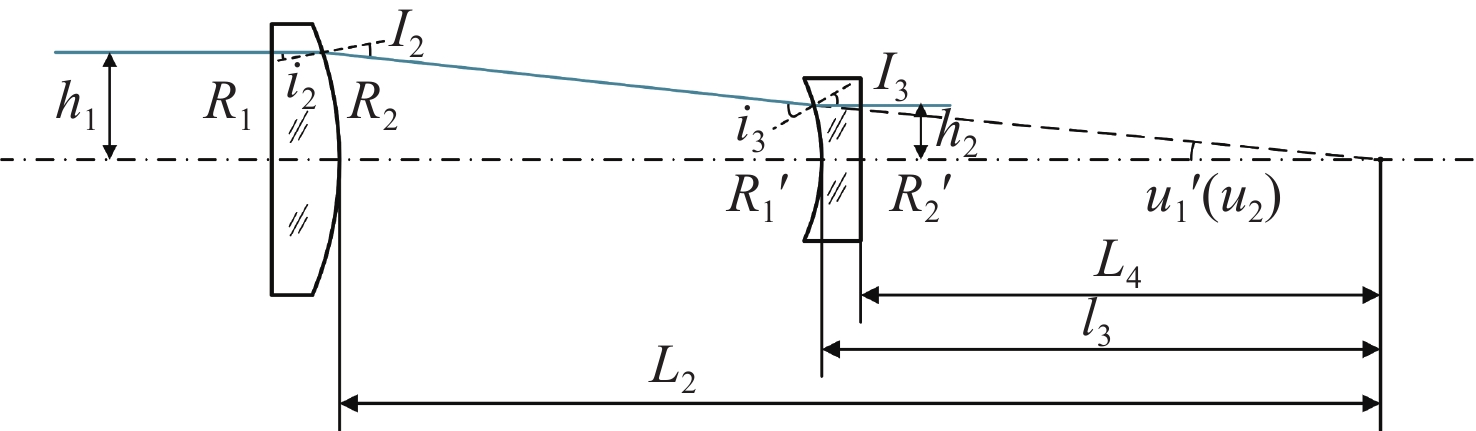
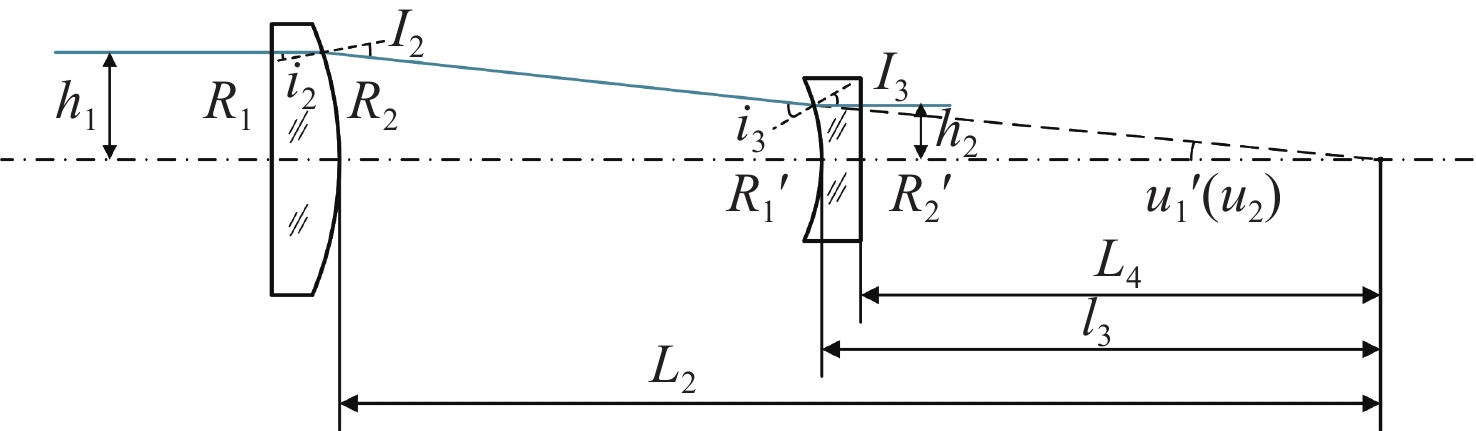
图 10 光线追迹法补偿光斑形状原理图
Figure 10. The principle diagram of light spot shape compensat-on by ray tracing method
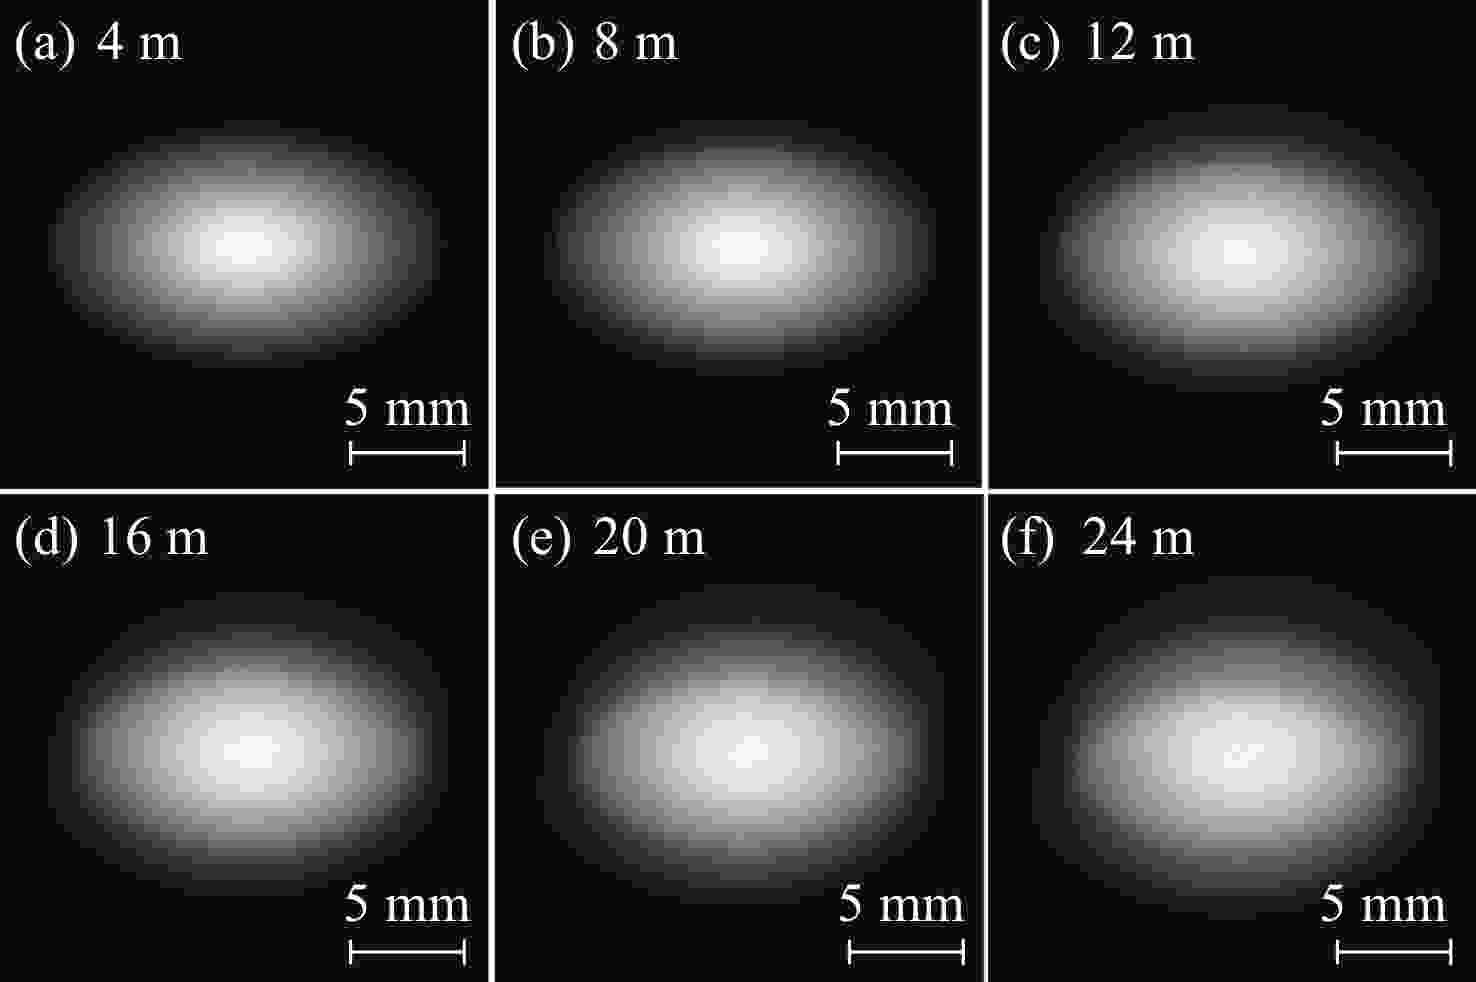
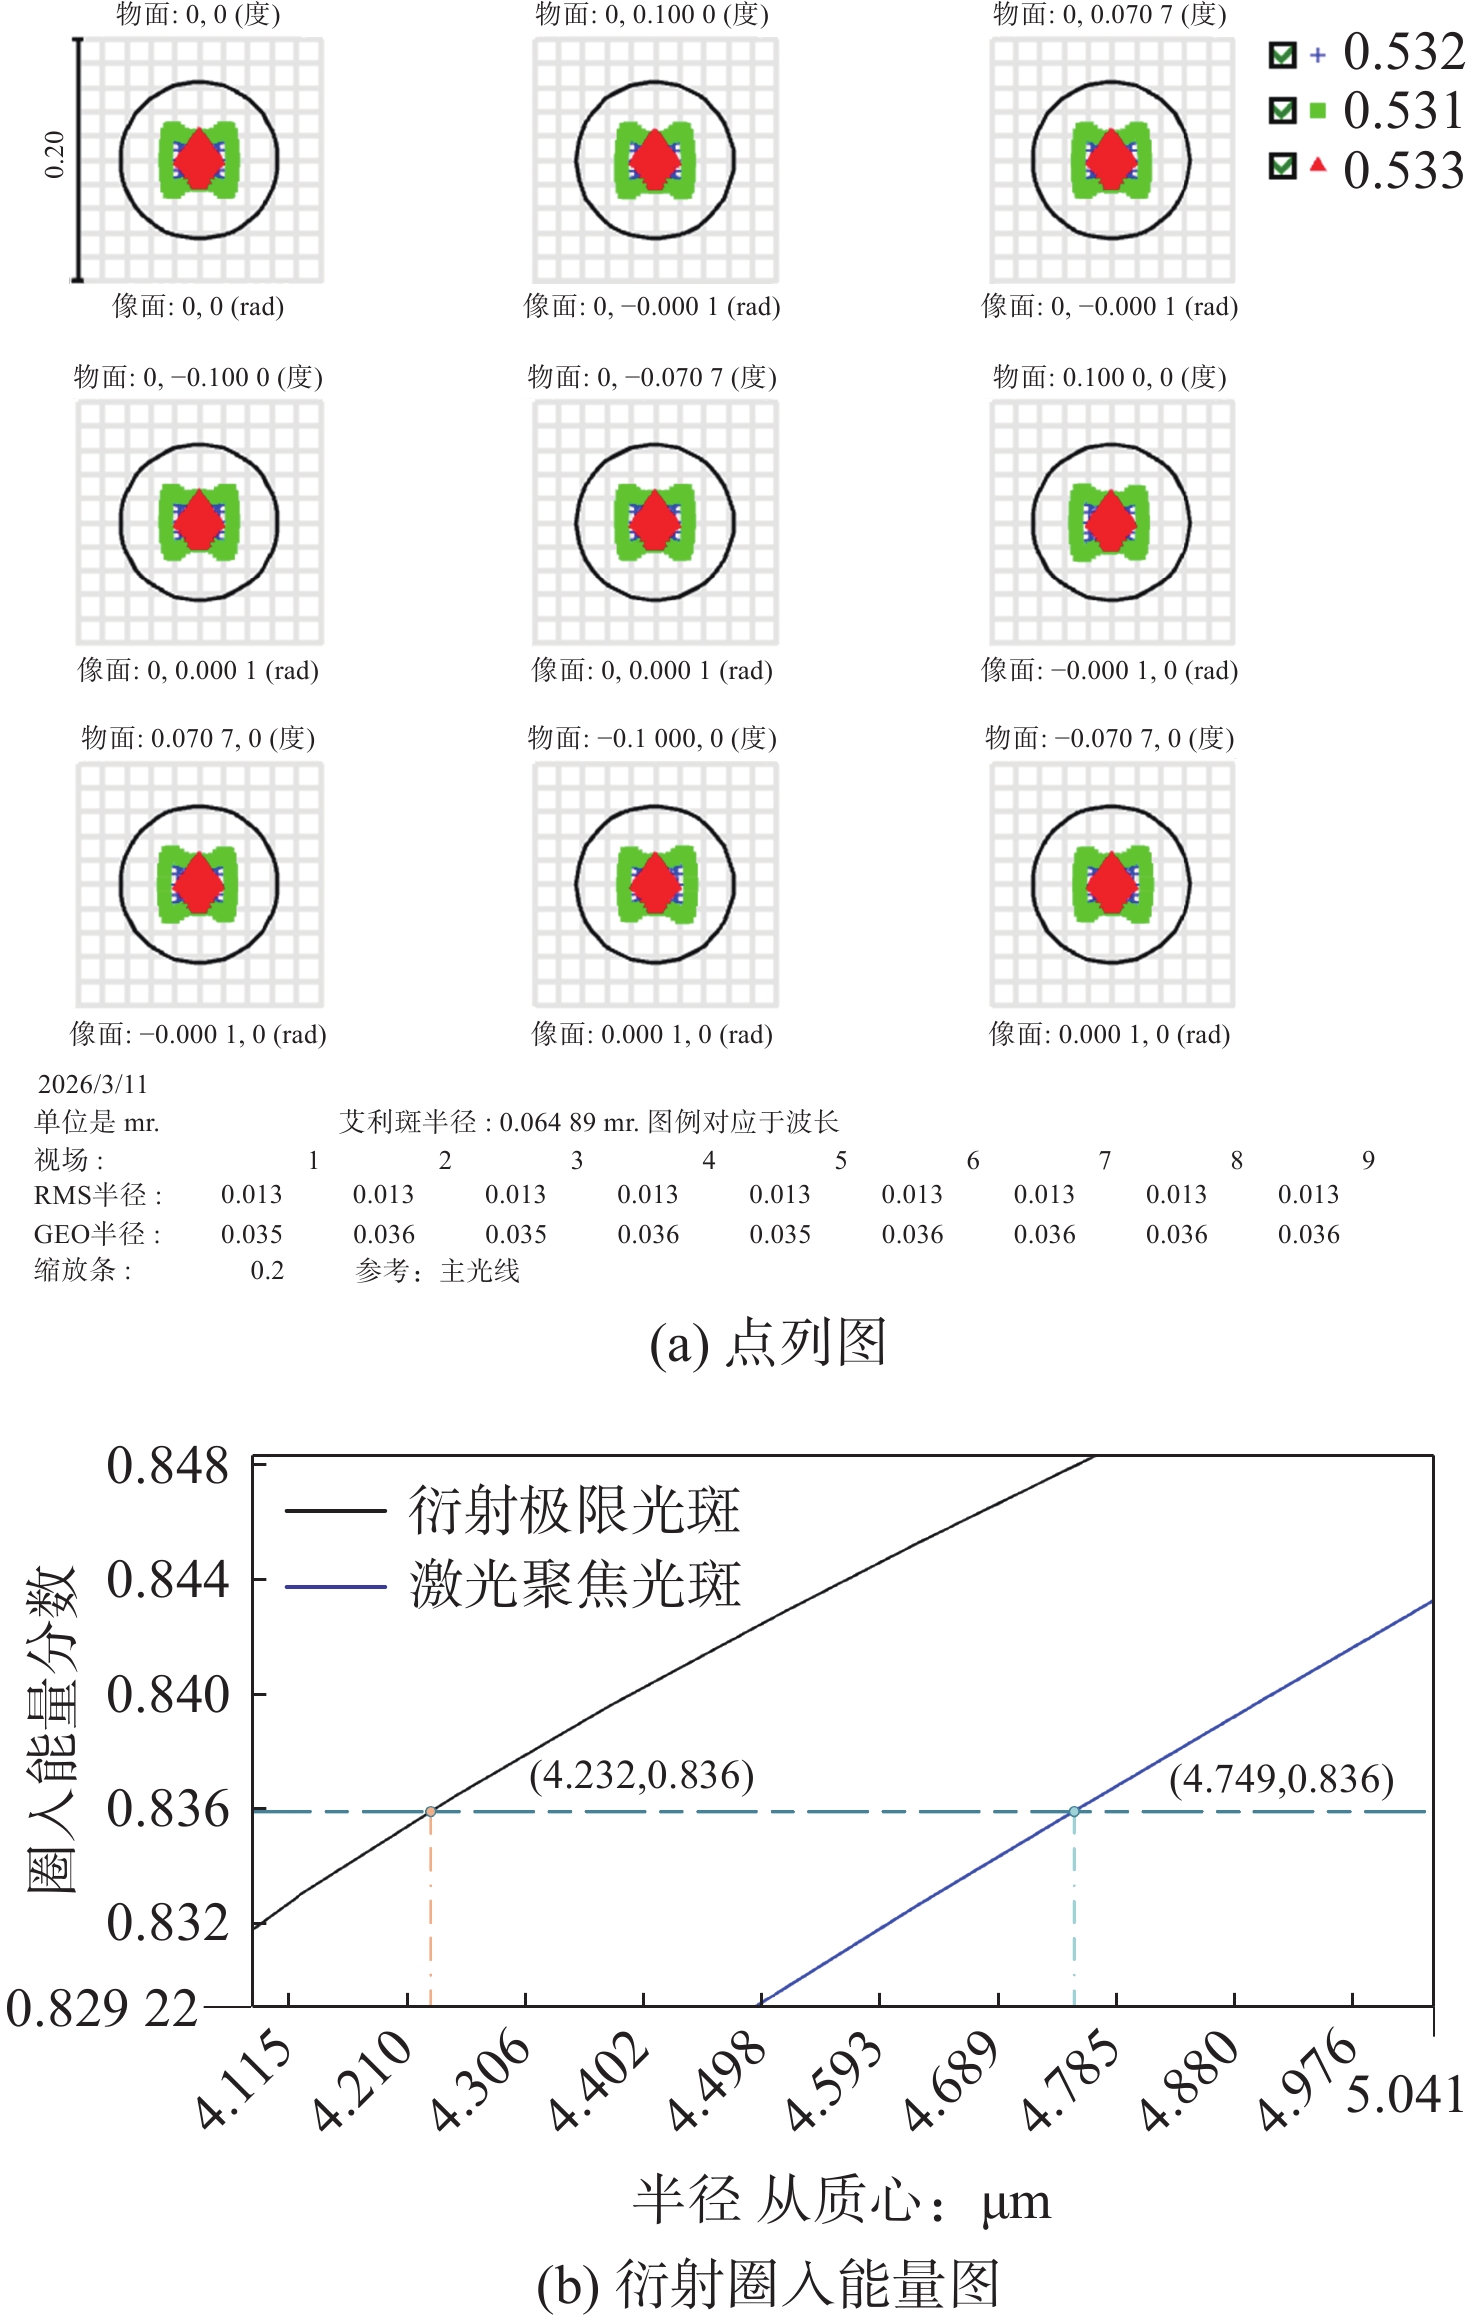
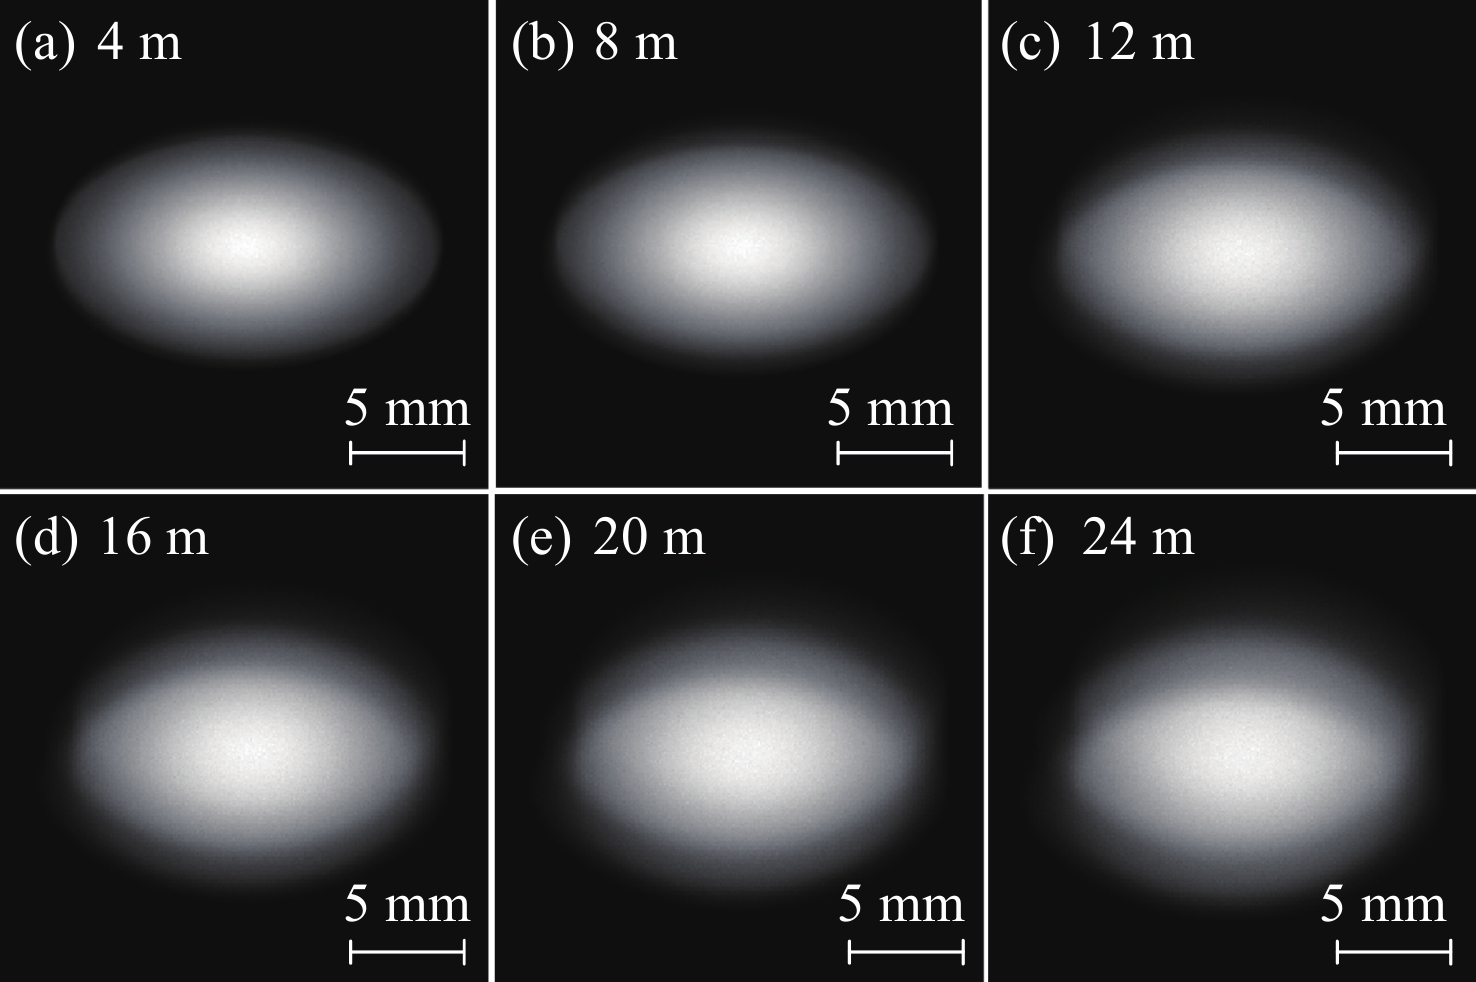
图 12 补偿发散角后不同距离下的几何光斑图
Figure 12. Geometric spot diagrams at different distances after compensating the divergence angle
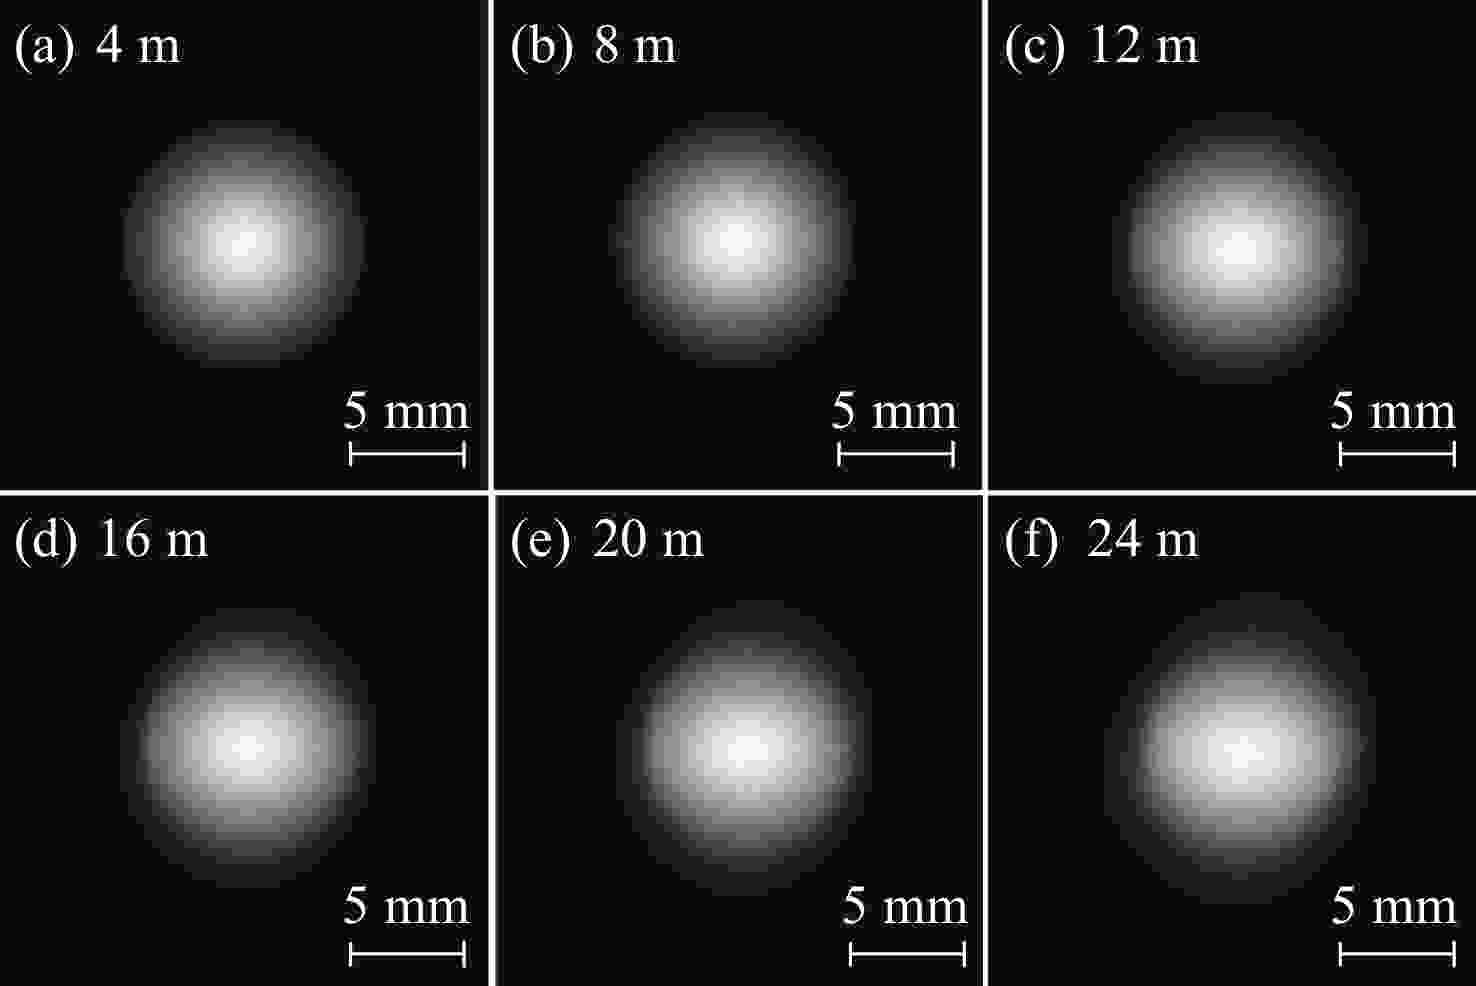
图 13 补偿光斑形状后不同距离下的几何光斑图
Figure 13. Geometric spot diagram at different distances after compensating spot shape
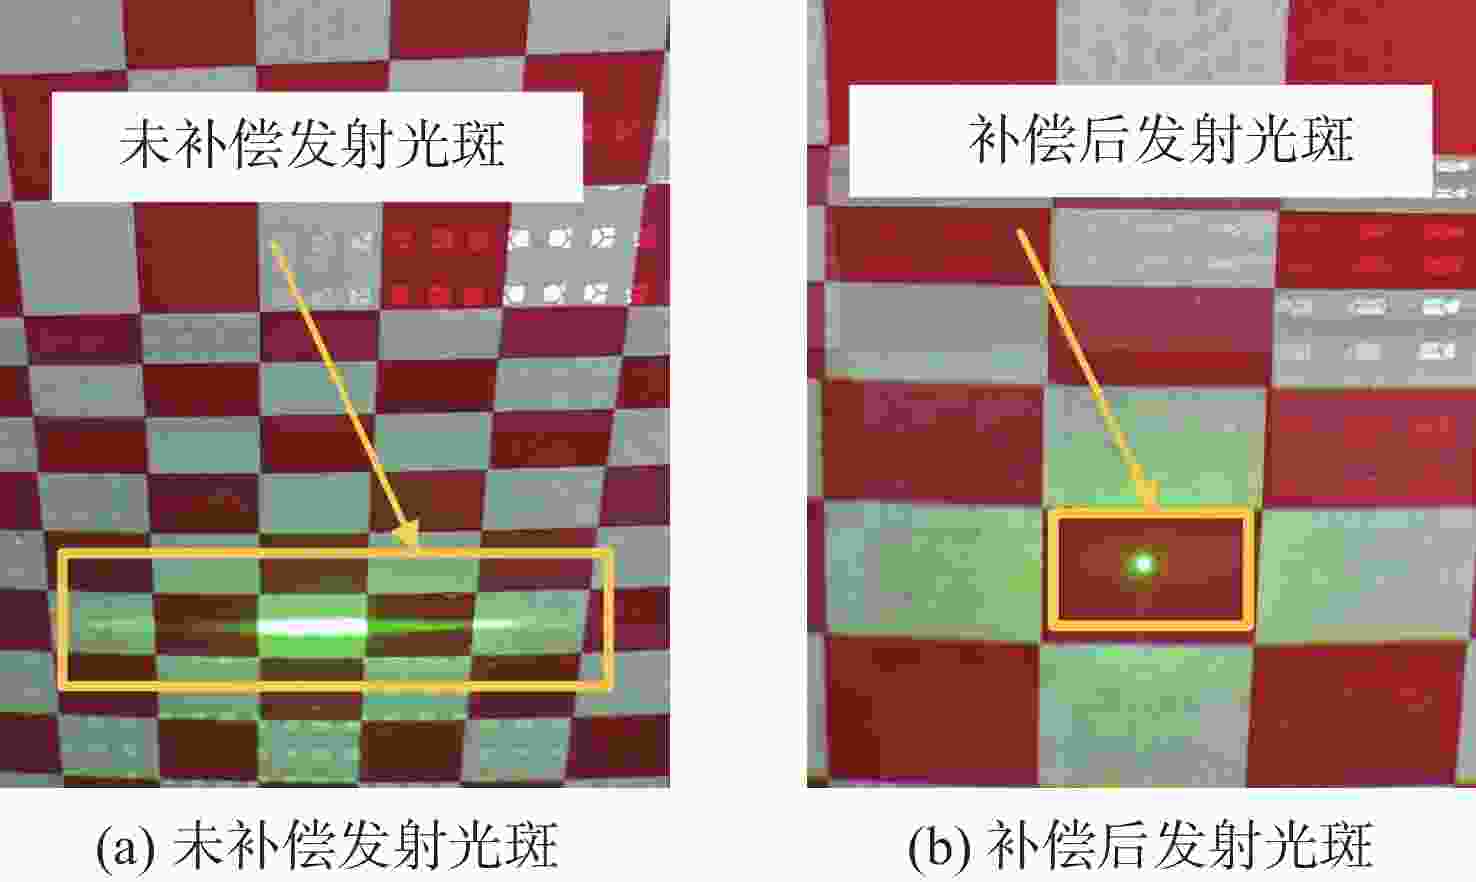
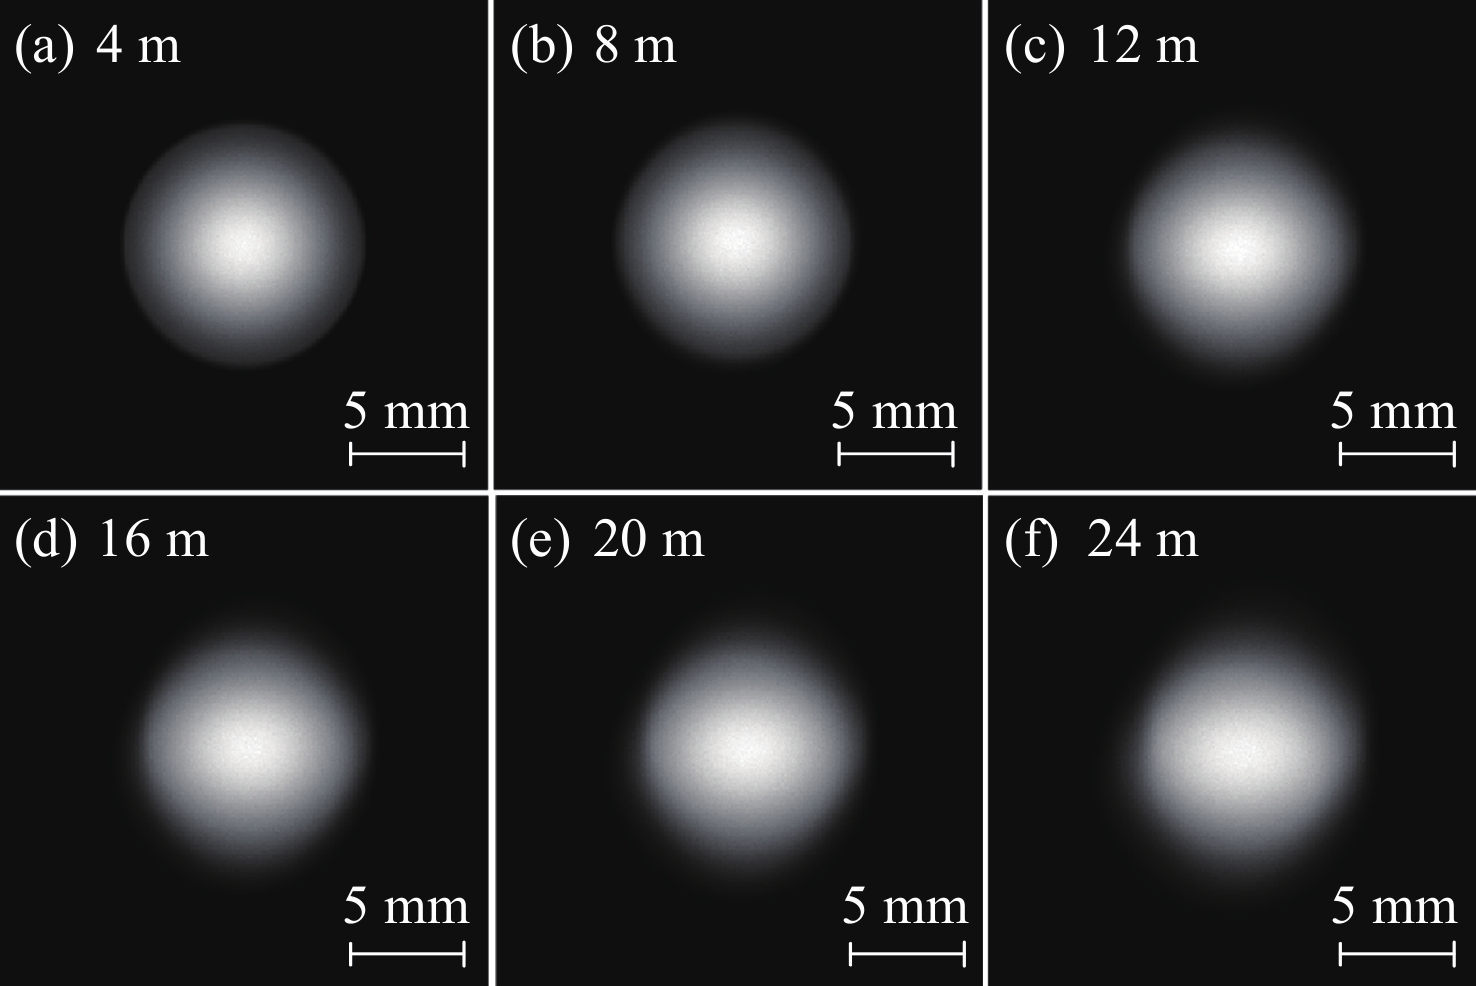
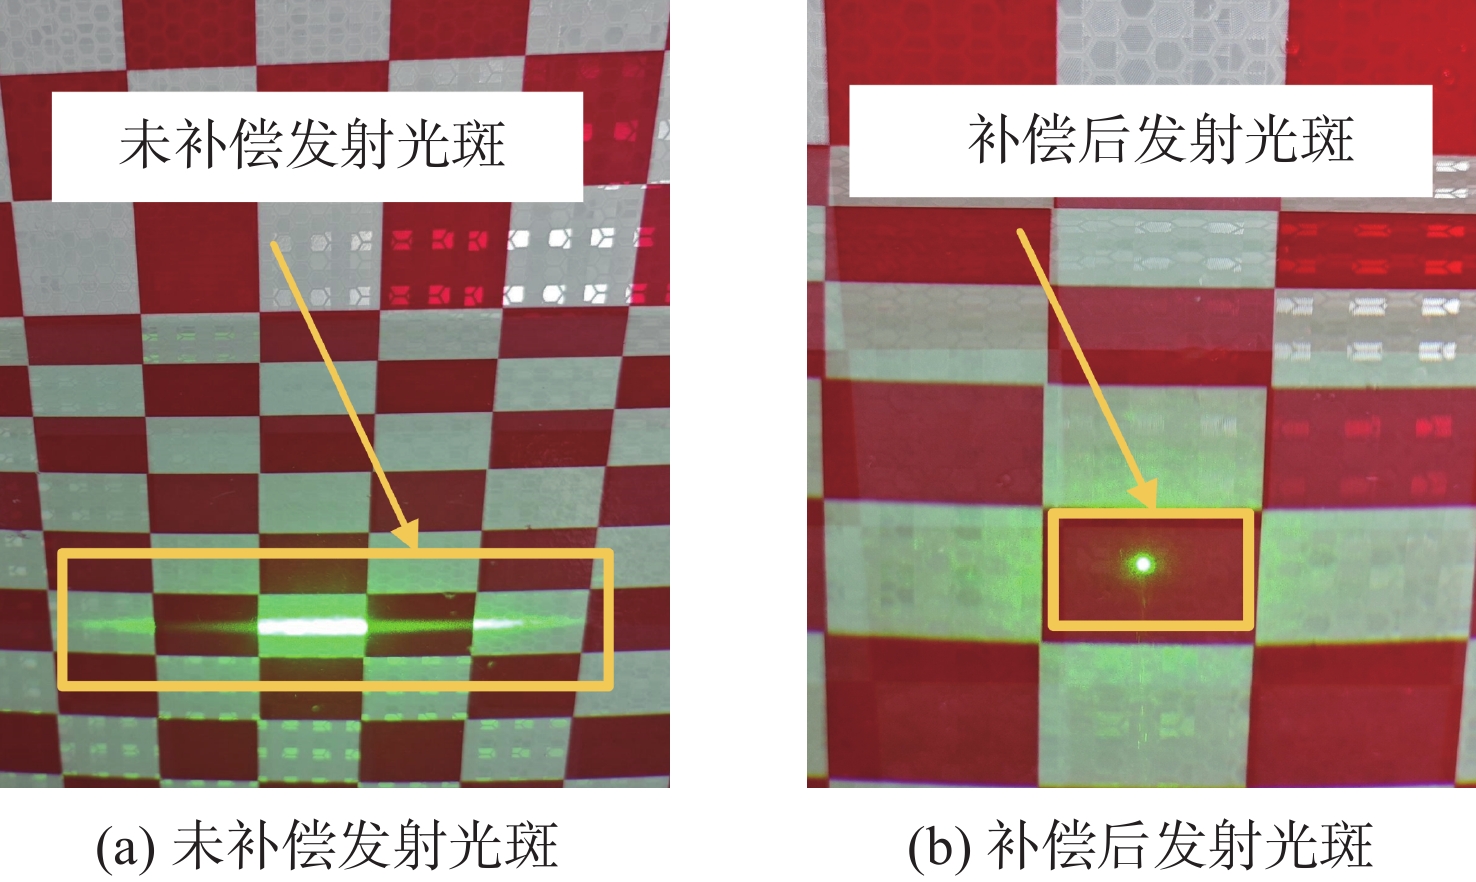
图 18 水下测距实验光斑补偿前后对比图
Figure 18. Comparison diagram before and after spot compensa-tion in underwater ranging experiment
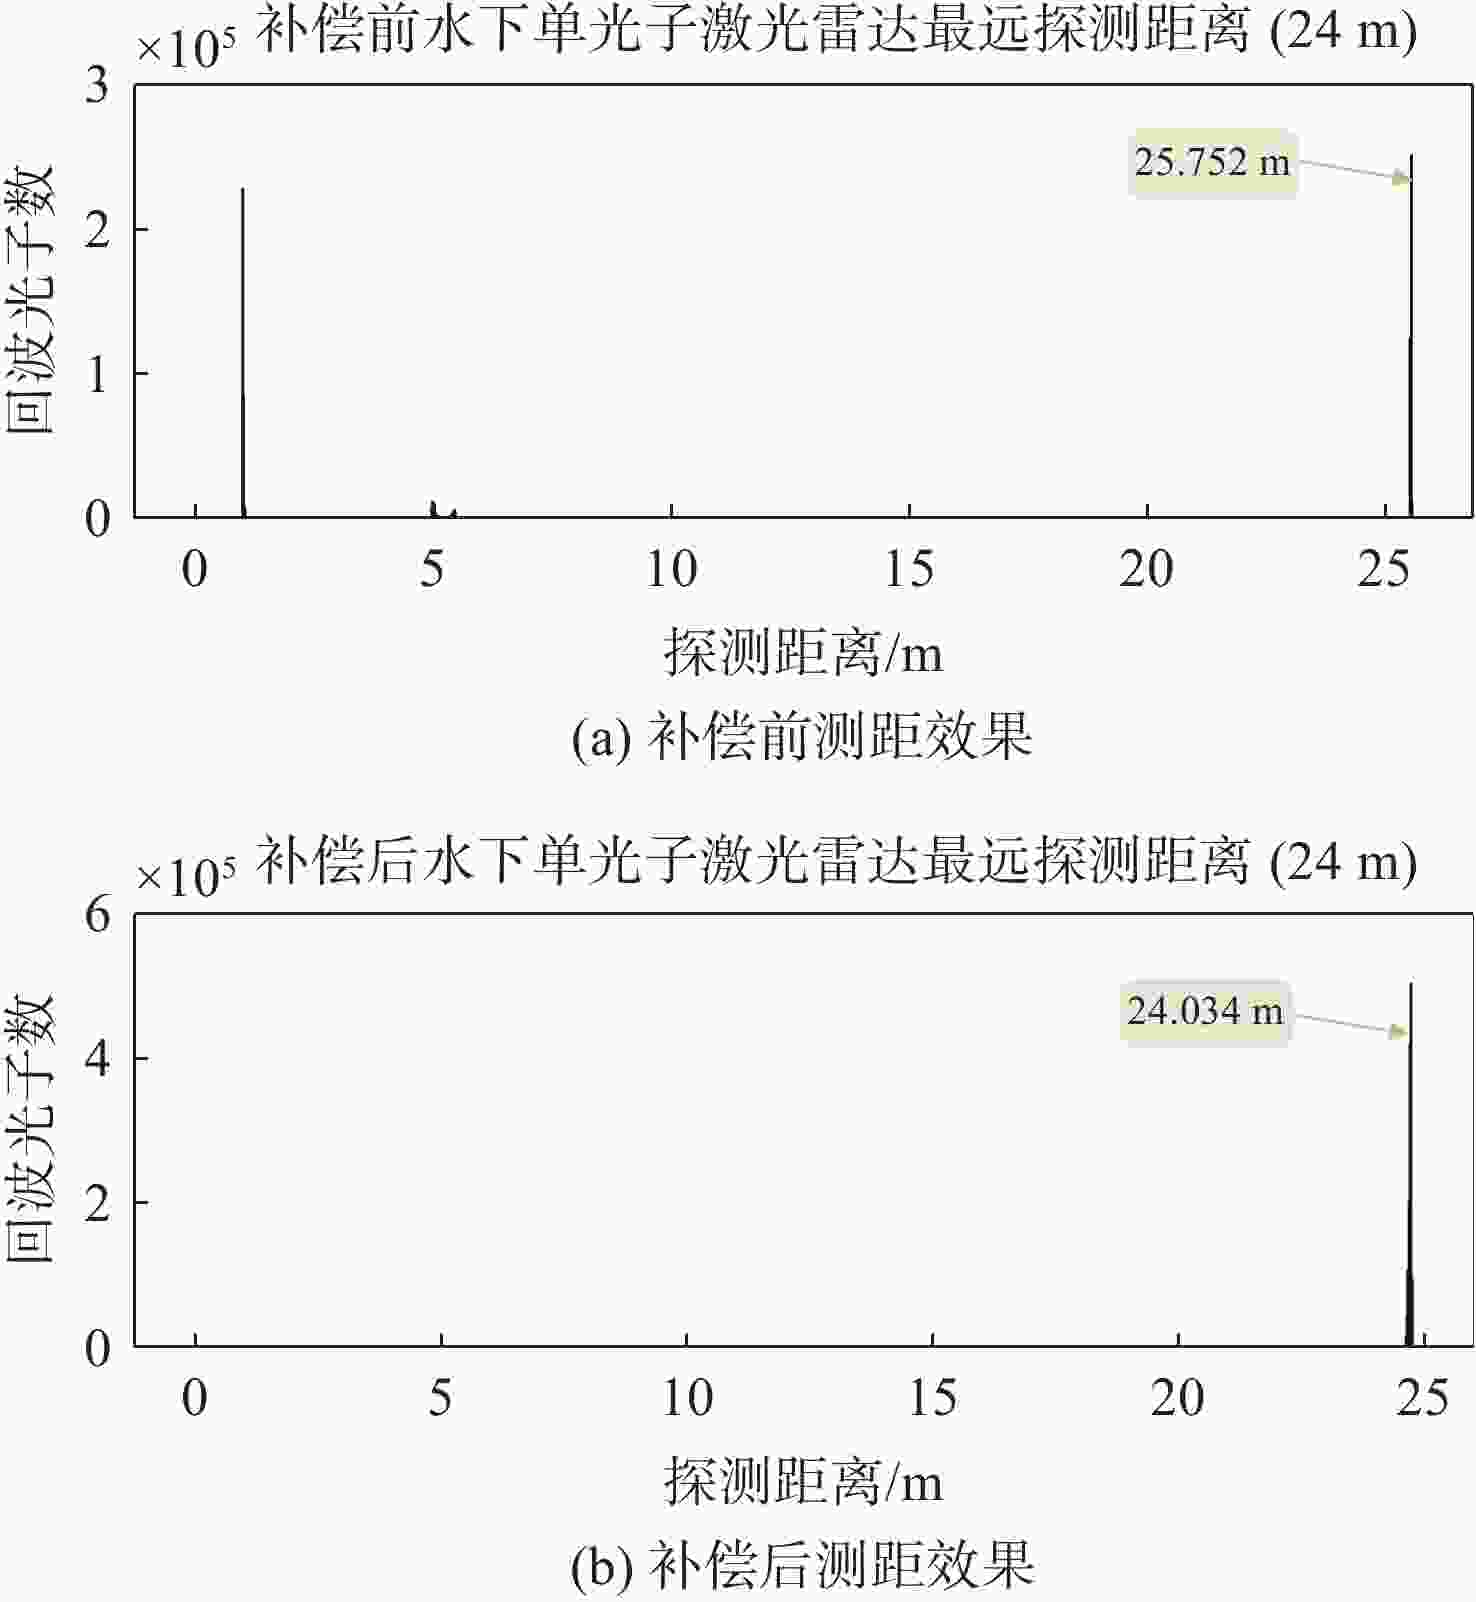
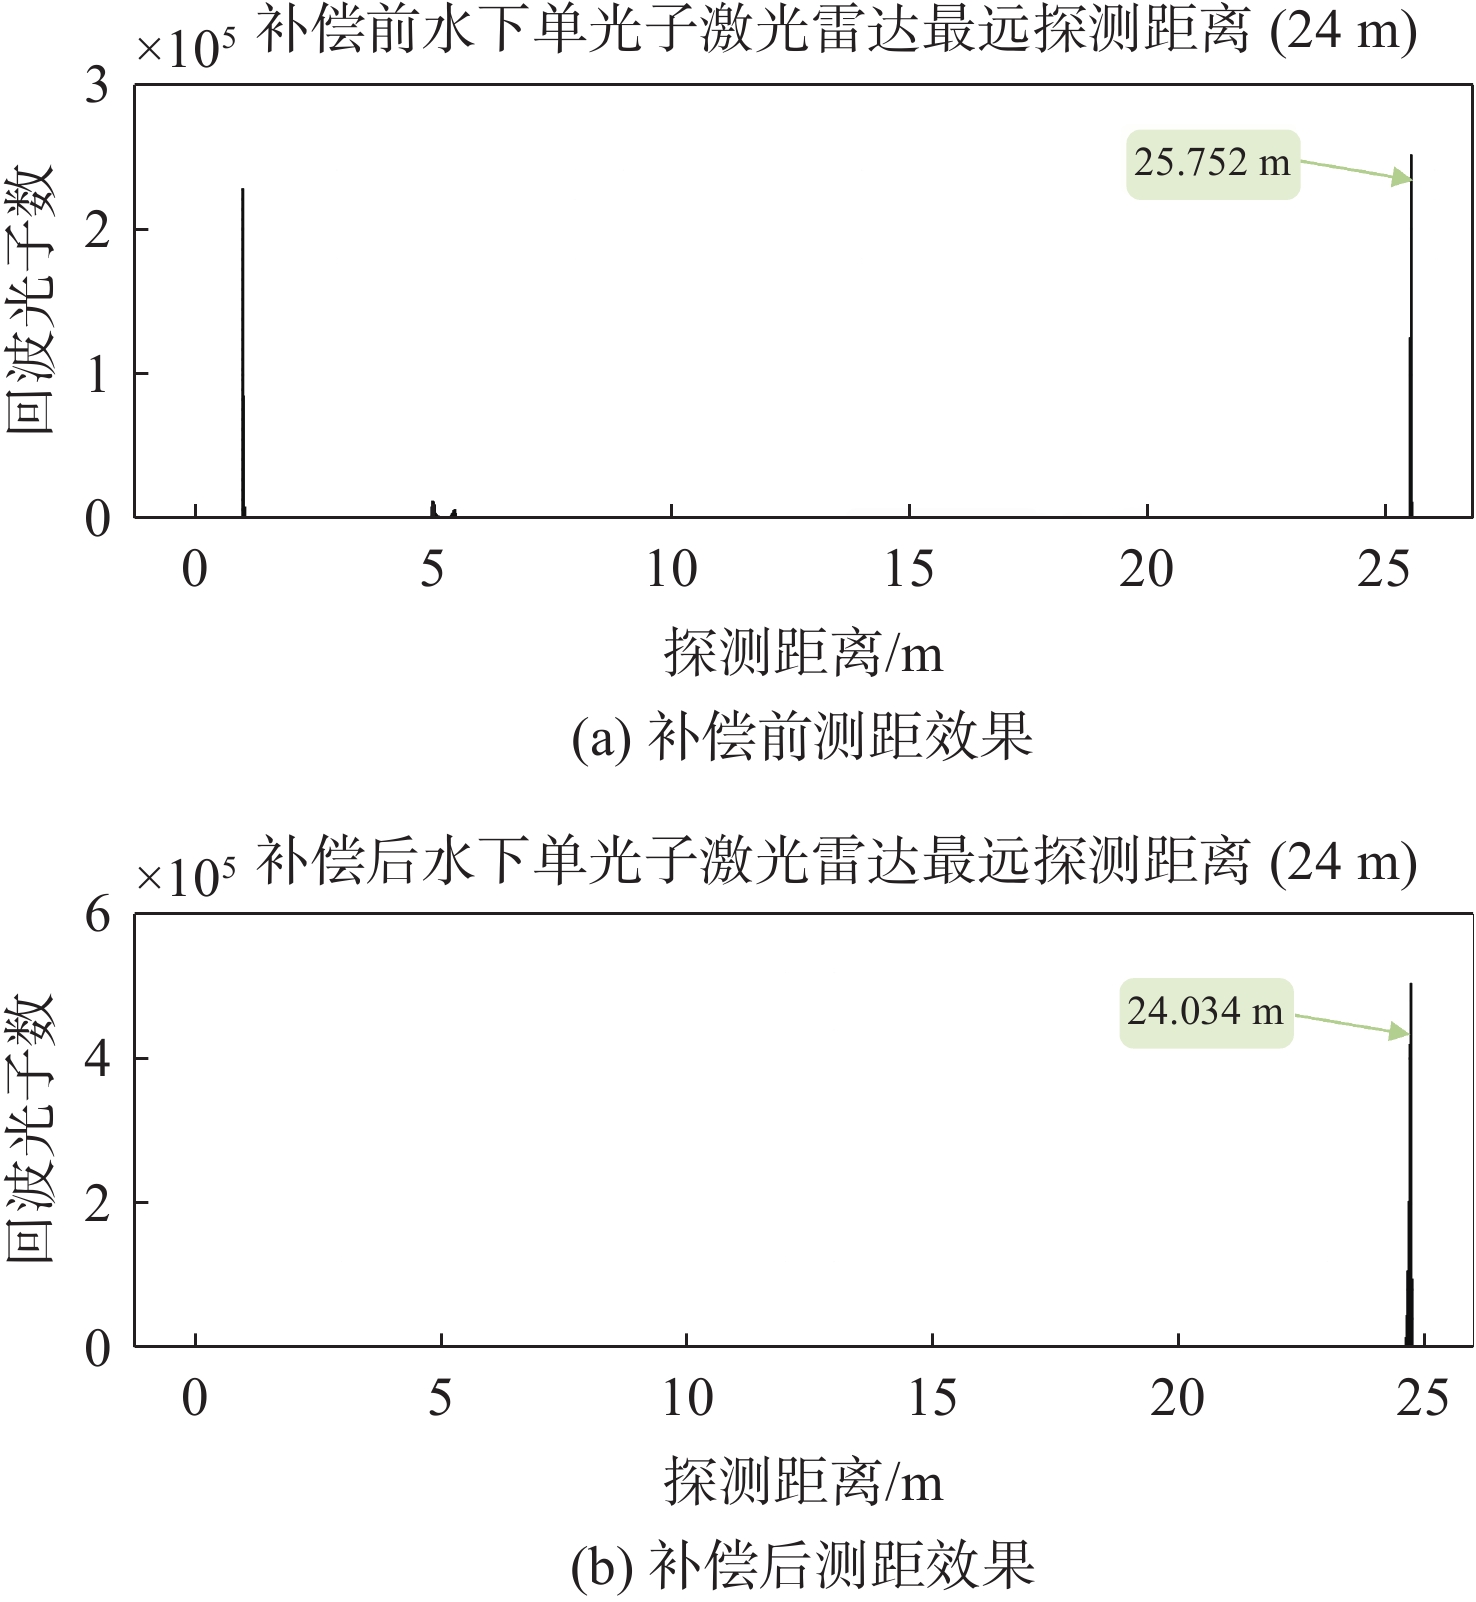
图 19 水下最大探测距离实验结果
Figure 19. Experimental results of maximum underwater detection distance
表 1 水下单光子激光雷达光学系统指标
Table 1. Optical system index underwater single photon lidar
指标 参数 工作波段 532±1nm 发散角 <0.1mrad 口径 ≥10mm 探测距离 >24m 扫描角度 0°~110° 传输效率 >90% 尺寸 220mm-450mm(直径-长度)  下载: 导出CSV
表 2 系统传输效率
Table 2. System transmission efficiency
膜系 传输效率 未镀膜 41.06% 0.99增透膜 85.12% 0.995增透膜 90.43%
下载: 导出CSV
表 3 水下单光子激光雷达系统参数
Table 3. Parameters of underwater single-photon laser radar system
指标 参数 脉冲能量 >5μJ 重复频率 >20kHz 脉宽 <0.85ns 平均输出功率 >100mW 单脉冲峰值功率 >7kW 接收孔径 25mm 探测效率 25%@532nm 暗记数 0.7Mcps
下载: 导出CSV
-
[1] 李晓亮, 刘荣科, 王建军, 等. 基于单光子探测器的深空激光通信阵列[J]. 光学 精密工程, 2022, 30(13): 1534-1541.LI X L, LIU R K, WANG J J, et al. Deep-space laser communications telescope array based on single photon detector[J]. Optics and Precision Engineering, 2022, 30(13): 1534-1541. (in Chinese). [2] 宗思光, 杨劭鹏, 张鑫, 等. 复杂水文微弱多目标激光探测仿真与实验[J]. 中国光学(中英文), 2024, 17(3): 560-571.ZONG S G, YANG SH P, ZHANG X, et al. Simulation and experiment of weak multi-target laser detection in complex hydrology[J]. Chinese Optics, 2024, 17(3): 560-571. (in Chinese). [3] CARESS D W, MARTIN E J, RISI M, et al. The MBARI low-altitude survey system for 1-cm-scale seafloor surveys in the deep ocean[J]. IEEE Journal of Oceanic Engineering, 2025, 50(3): 1573-1584. [4] 刘广平, 杨靖, 金永平, 等. 深海生物采样技术研究进展与发展趋势[J/OL]. 中国机械工程, 2026: 1-17 (2026-01-29). https://link.cnki.net/urlid/42.1294.TH.20260128.1751.003. (查阅网上资料,未找到本条文献引用日期信息,请确认).LIU G P, YANG J, JIN Y P, et al. Progress and perspective of deep-sea biological sampling technology[J/OL]. China Mechanical Engineering, 2026: 1-17 (2026-01-29). https://link.cnki.net/urlid/42.1294.TH.20260128.1751.003. (in Chinese). [5] SHANGGUAN M J, GUO Y R, LIAO ZH Y. Shipborne single-photon fluorescence oceanic lidar: instrumentation and inversion[J]. Optics Express, 2024, 32(6): 10204-10218. [6] 程藻. 基于自适应后向散射滤波技术的激光雷达水下目标探测研究[D]. 武汉: 华中科技大学, 2016.CHENG Z. Research on underwater lidar detection based on adaptive backscattering filtering technique[D]. Wuhan: Huazhong University of Science & Technology, 2016. (in Chinese). [7] 华康健. 水下光子计数激光雷达关键技术研究[D]. 成都: 中国科学院大学(中国科学院光电技术研究所), 2021.HUA K J. Research on key technologies of underwater photon-counting LIDAR[D]. Chengdu: University of Chinese Academy of Sciences (Institute of Optics and Electronics, Chinese Academy of Sciences), 2021. (in Chinese). [8] LI ZH, HAN Y Q, WU L C, et al. Towards an ultrafast 3D imaging scanning LiDAR system: a review[J]. Photonics Research, 2024, 12(8): 1709-1729. [9] SHANGGUAN M, LI Y, MO Y C, et al. Compact underwater single-photon imaging lidar[J]. Optics Letters, 2025, 50(6): 1957-1960. [10] 王宇航, 王新宇, 张景辉, 等. 水下三维光学成像探测技术综述及展望[J]. 激光与光电子学进展, 2024, 61(22): 2200003.WANG Y H, WANG X Y, ZHANG J H, et al. Review and prospect of underwater 3D imaging detection[J]. Laser & Optoelectronics Progress, 2024, 61(22): 2200003. (in Chinese). [11] SOLONENKO M G, MOBLEY C D. Inherent optical properties of Jerlov water types[J]. Applied Optics, 2015, 54(17): 5392-5401. [12] WENG ZH W, SUN J X, YANG ZH F, et al. Measurement of inherent optical properties of water based on multiple scattering profiles using underwater off-axis single-photon lidar[J]. Optics Letters, 2024, 32(27): 48035-48050. [13] HAN W H, LEE S W, LIM J, et al. Design and feasibility study on a compact wide-field LiDAR optical system using polygonal mirrors[J]. Optics and Lasers in Engineering, 2025, 195: 109273. [14] 周广鹏. 水下连续光成像关键技术研究[D]. 长春: 中国科学院大学(中国科学院长春光学精密机械与物理研究所), 2025.ZHOU G P. Research on essential technologies in underwater continuousoptical imaging[D]. Changchun: University of Chinese Academy of Sciences (Changchun Institute of Optics, Fine Mechanics and Physics, Chinese Academy of Sciences), 2025. (in Chinese). [15] 李国浩, 王凌云, 桂云霆, 等. 紧凑型、大视场可见长波红外共孔径制导光学系统设计[J/OL]. 激光与光电子学进展, 2026: 1-18 (2026-04-10). https://link.cnki.net/urlid/31.1690.TN.20260409.0933.084.LI G H, WANG L Y, GUI Y T, et al. Common-aperture guidance optical system with a compact size and wide field of view for visible and long-wave infrared bands[J/OL]. Laser & Optoelectronics Progress, 2026: 1-18 (2026-04-10). https://link.cnki.net/urlid/31.1690.TN.20260409.0933.084. (in Chinese) (查阅网上资料,未找到本条文献引用日期信息,请确认). [16] 王文生, 刘冬梅. 应用光学[M]. 2版. 武汉: 华中科技大学出版社, 2019.WANG W SH, LIU D M. Applied Optics[M]. 2nd ed. Wuhan: Huazhong University of Science and Technology Press, 2019. (in Chinese). [17] YU X, DONG L ZH, LAI B H, et al. Automatic low-order aberration correction based on geometrical optics for slab lasers[J]. Applied Optics, 2017, 56(6): 1730-1739. [18] 刘才, 于信, 潘国涛, 等. 大口径多波段光束质量检测系统设计[J]. 中国光学(中英文), 2024, 17(4): 932-942.LIU C, YU X, PAN G T, et al. Design of large-aperture multi-band beam quality detection system[J]. Chinese Optics, 2024, 17(4): 932-942. (in Chinese). [19] 钟昆, 苏伟, 彭波, 等. 水下激光周视扫描4f发射光学系统设计[J]. 红外与激光工程, 2021, 50(3): 202002.ZHONG K, SU W, PENG B, et al. Design of 4f emission optical system for underwater laser circumferential scanning[J]. Infrared and Laser Engineering, 2021, 50(3): 202002. (in Chinese). [20] 熊芝, 钟陈小鹏, 张昊, 等. 基于多位姿标靶的激光跟踪姿态测量系统参数标定[J]. 光学 精密工程, 2025, 33(1): 13-24.XIONG ZH, ZHONG CH X P, ZHANG H, et al. Parameter calibration of laser tracking attitude measurement system based on multi-position targets[J]. Optics and Precision Engineering, 2025, 33(1): 13-24. (in Chinese). [21] 董大鹏, 于信, 汪逸群, 等. 0.05~0.1MPa宽气压环境下校准光源光学系统设计[J]. 光学 精密工程, 2023, 31(8): 1124-1135.DONG D P, YU X, WANG Y Q, et al. Optical system design of calibration light source in 0.05-0.1MPa wide atmospheric pressure environment[J]. Optics and Precision Engineering, 2023, 31(8): 1124-1135. (in Chinese). -

 下载:

计量
- 文章访问数: 1
- HTML全文浏览量: 2
- PDF下载量: 0
- 被引次数: 0
